
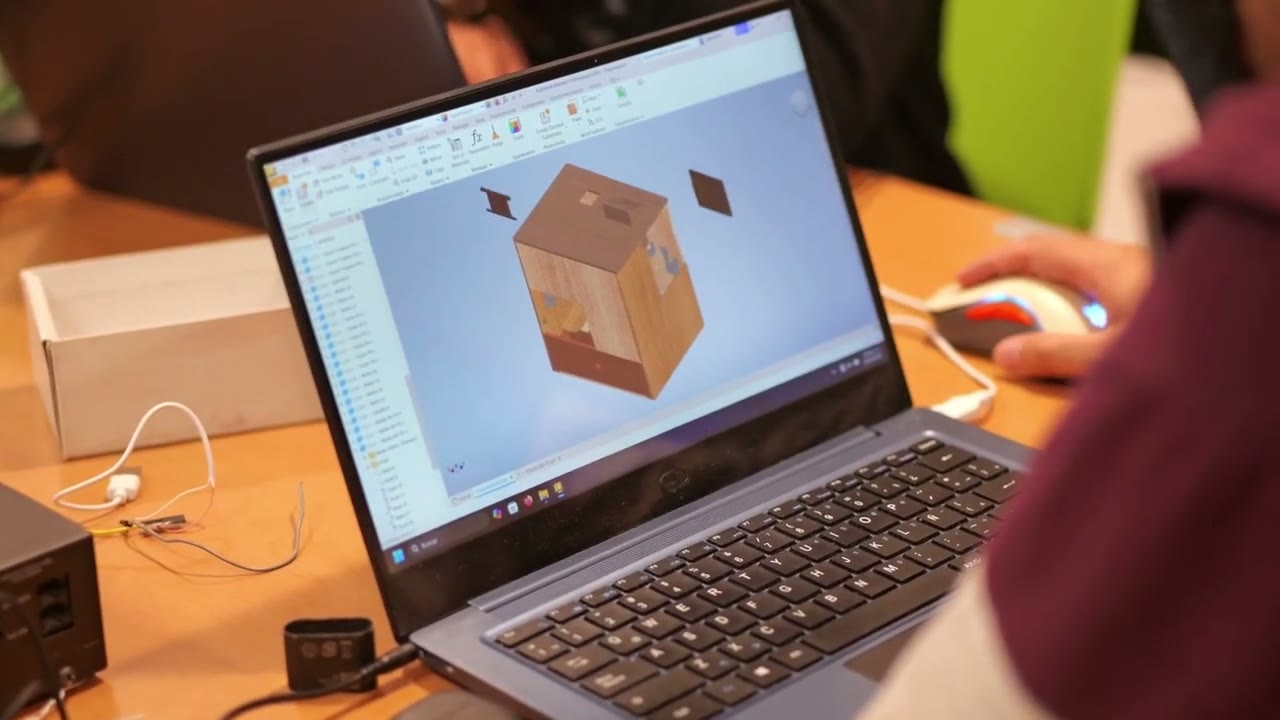
I’m a mechanical engineer by training. I learned technical drawing with pen and paper, then CAD. Seeing AI move from work on a screen to work in the physical world made me want to get my hands on the hardware.
The moment that got me.
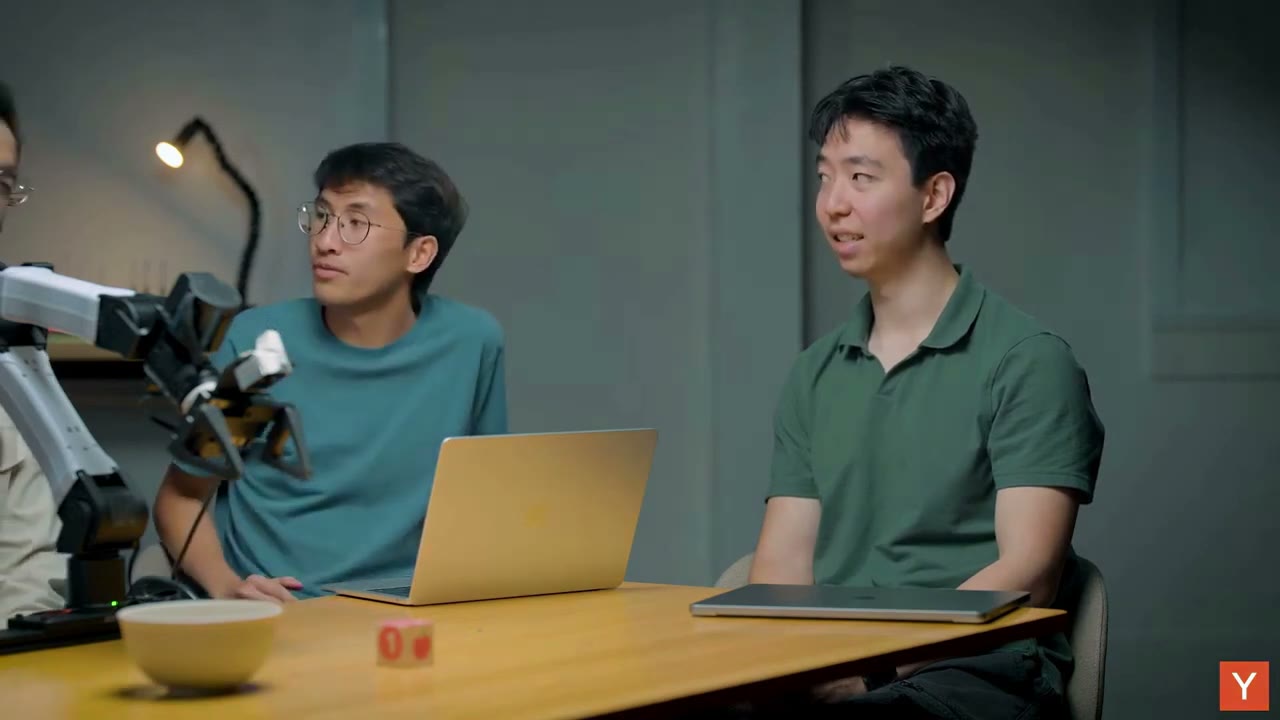
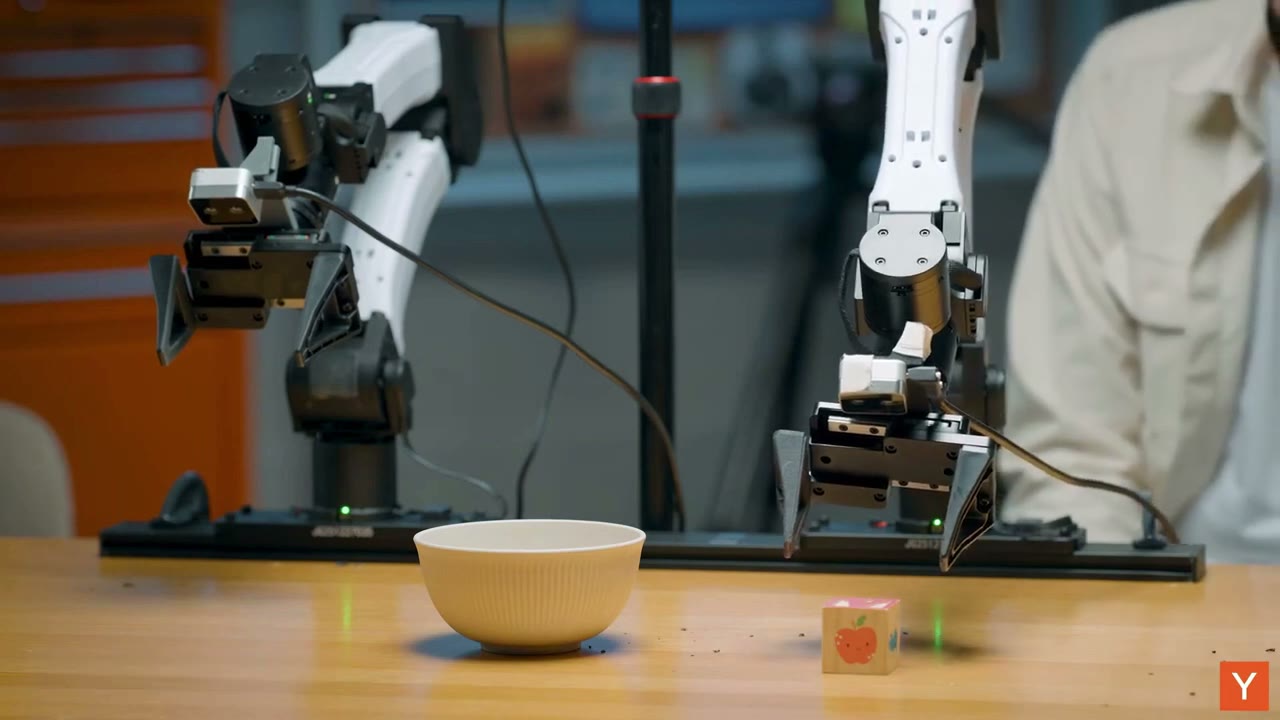
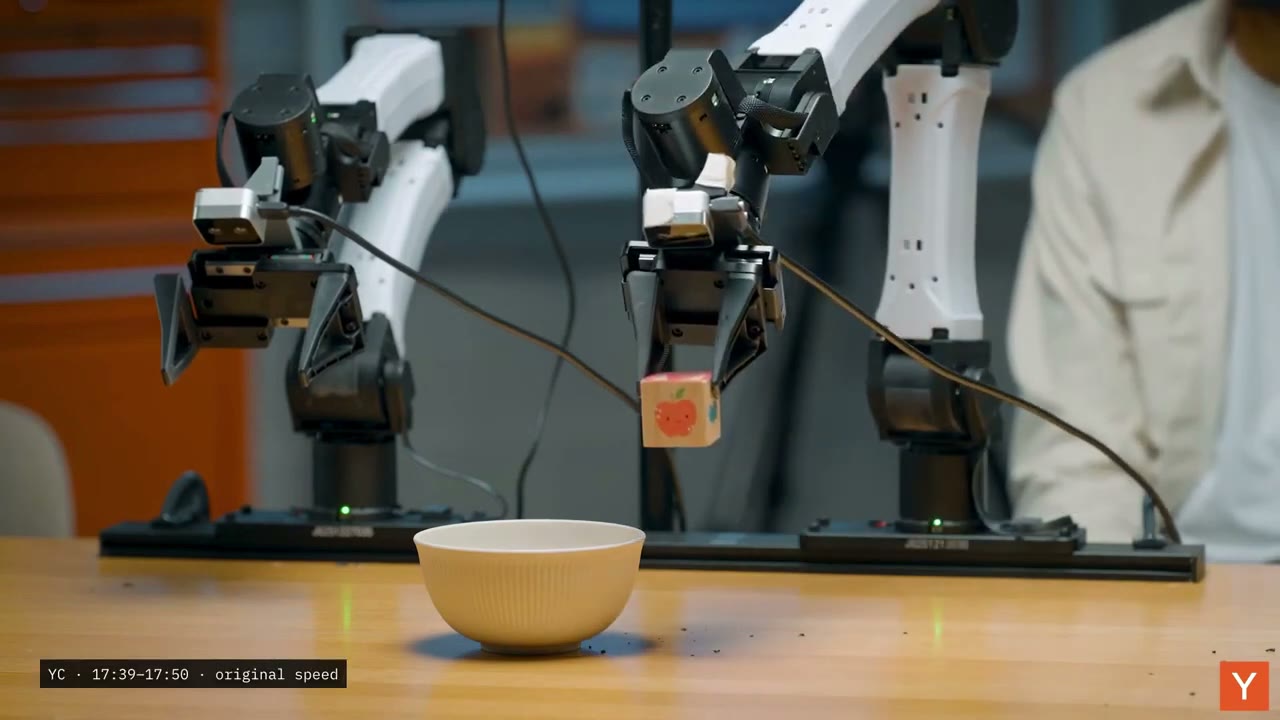
In a robot demonstration, I watched AI use a camera view to guide robot arms through a pick-and-place task. A block going into a bowl sounds small. Watching it happen made the possibilities feel different from another software demo.
Episode 1 is my commentary on that moment. The interview and robot demonstration are source footage from Y Combinator, not a robot system I built.
 ▶ Watch source video
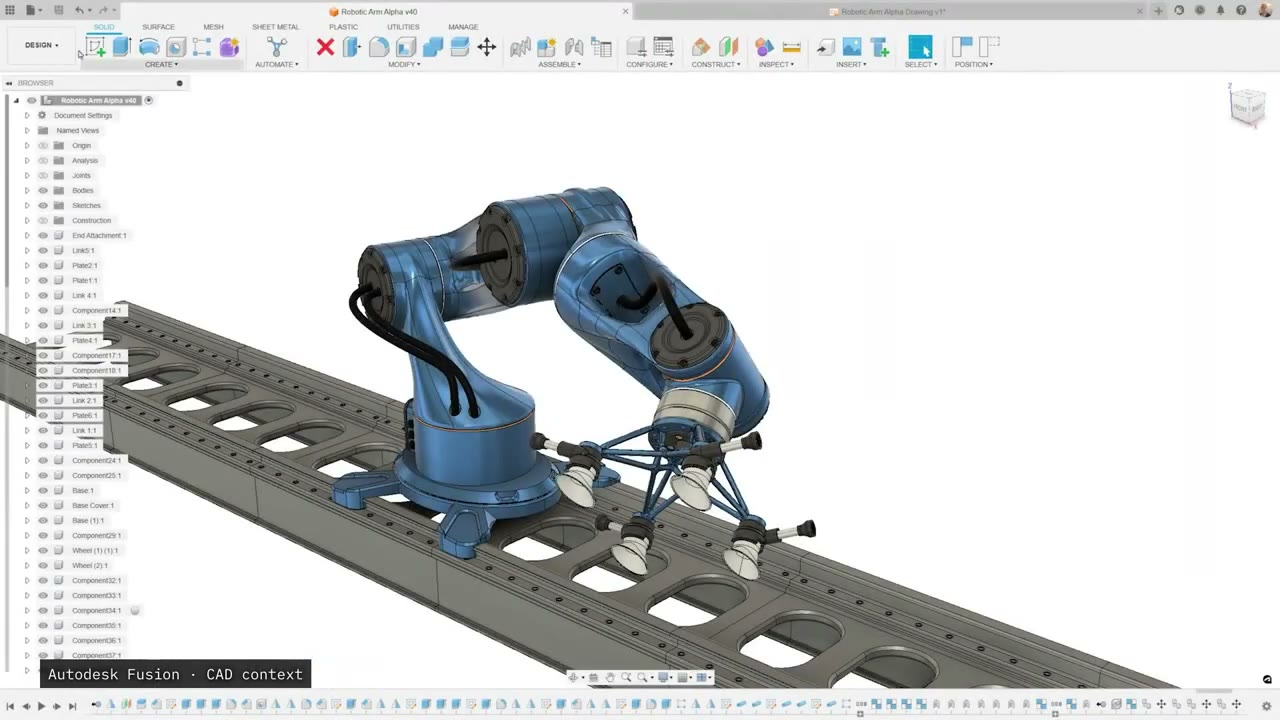
One demo. Plenty of questions.
A successful pick-and-place doesn’t tell me how reliable a system is outside a carefully arranged demonstration. I want to find out what I can make this technology do myself — with small experiments, mistakes and the occasional working result.
So I’m starting in public.
This series follows that curiosity from AI agents into robotics and hardware. The next step was closer to hand than a pair of robot arms: an old phone, a room map and a virtual robot.
Documentary commentary by Lukas Timm. AI-assisted production, including my own cloned voice and an AI-generated illustrative thumbnail. Original robot demonstration: Y Combinator.
Watch episode 01 on YouTube ↗