
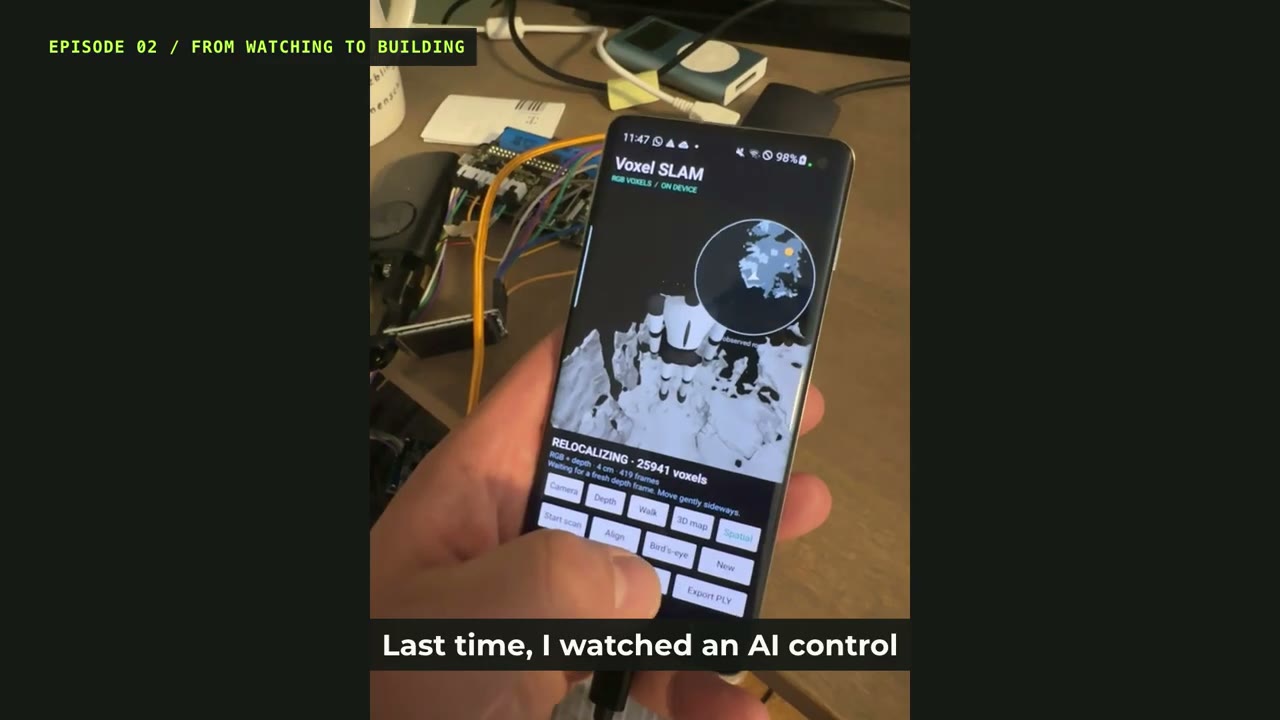
After watching AI control robot arms, I wanted to build something myself. I started with an old Samsung S10 and a coding session with Astra.
A room becomes a small world.
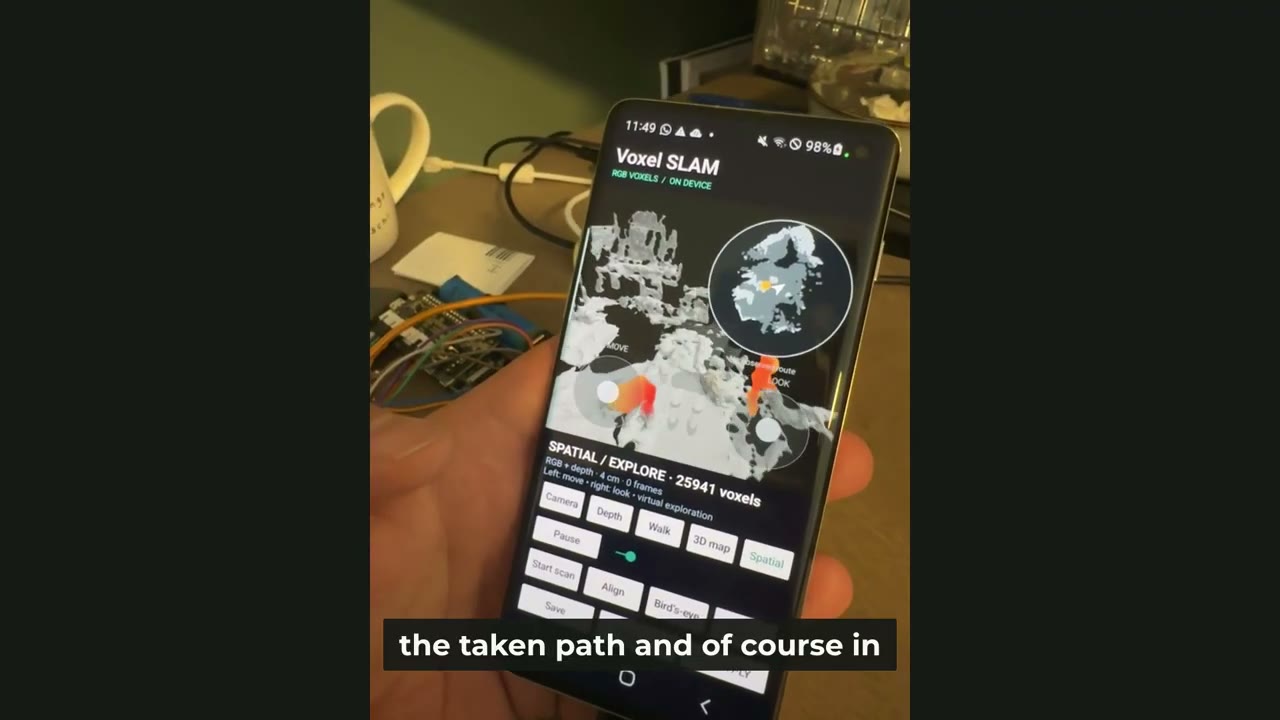
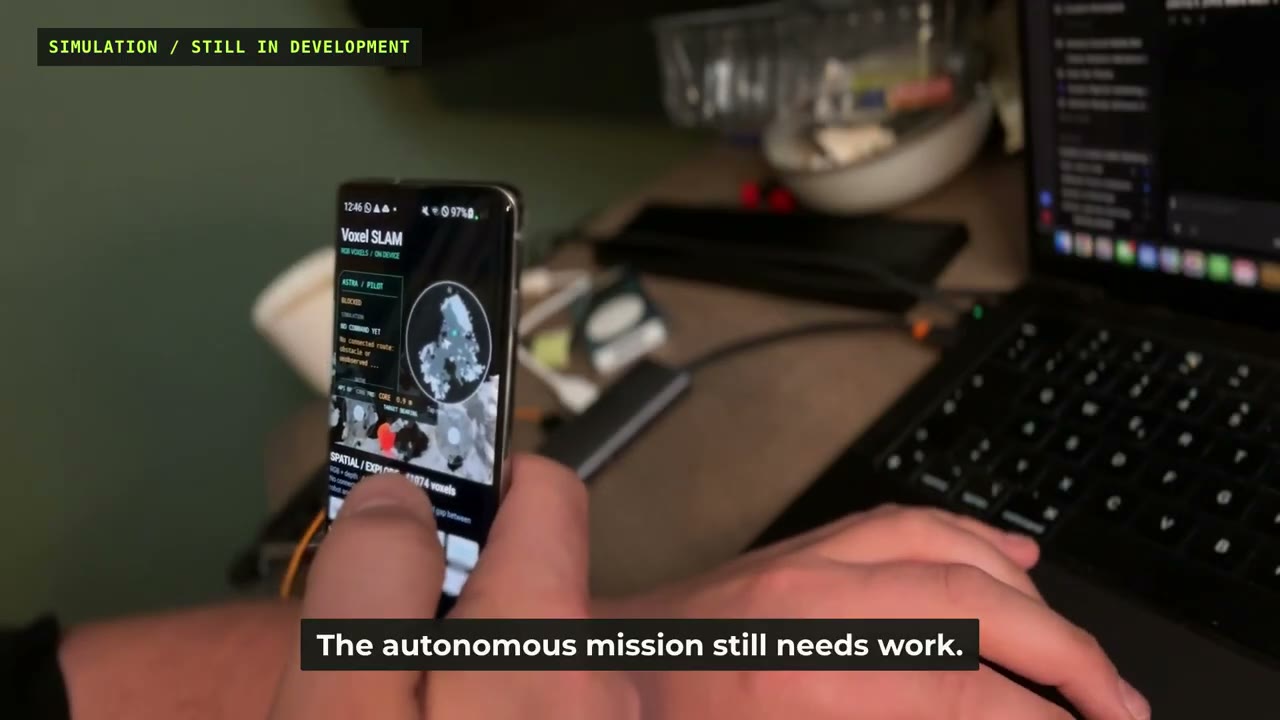
I can scan my office, watch a virtual humanoid move through the map, replay the path, and explore the saved room like a little game. That gives me something concrete to build on: a map I can inspect and a route I can replay.
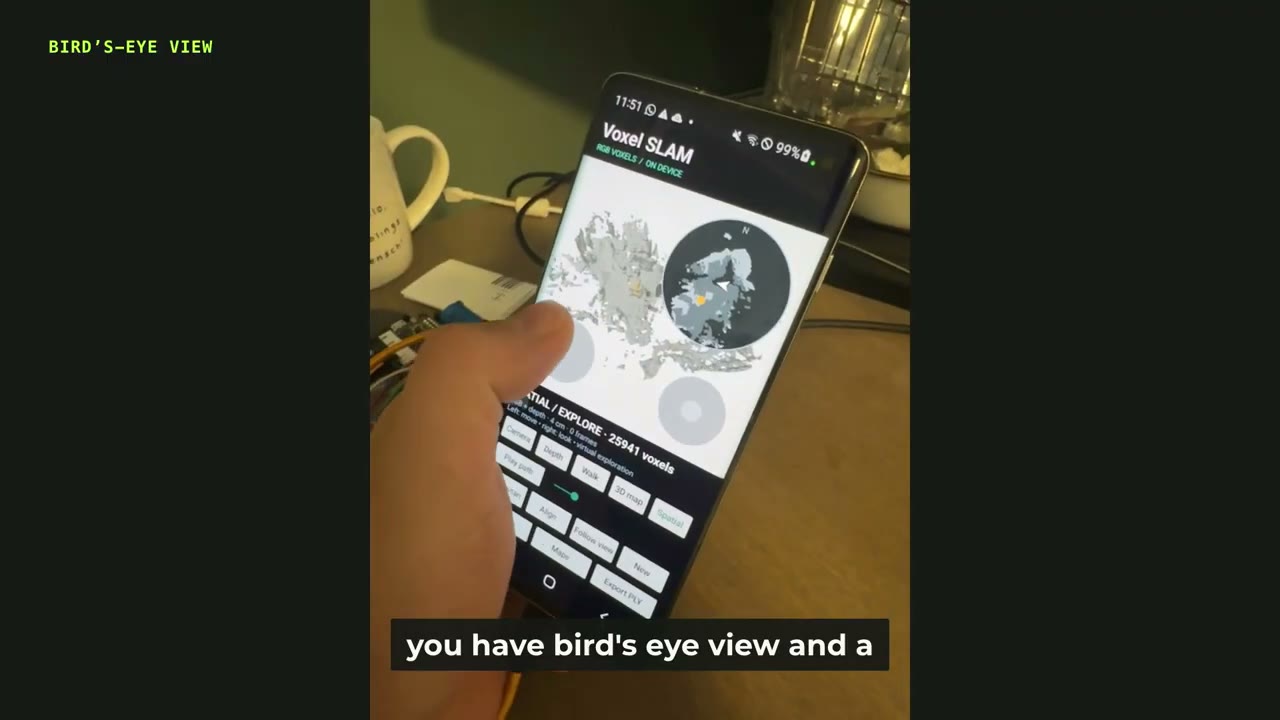
Then I tried a mission.
The next test was an autonomous pickup task. That part doesn’t work yet — the attempt is in the episode. The phone handles the mapping and route checks; Astra receives state and route information and chooses the next step. For now, the robot is virtual.
Next: a physical body.
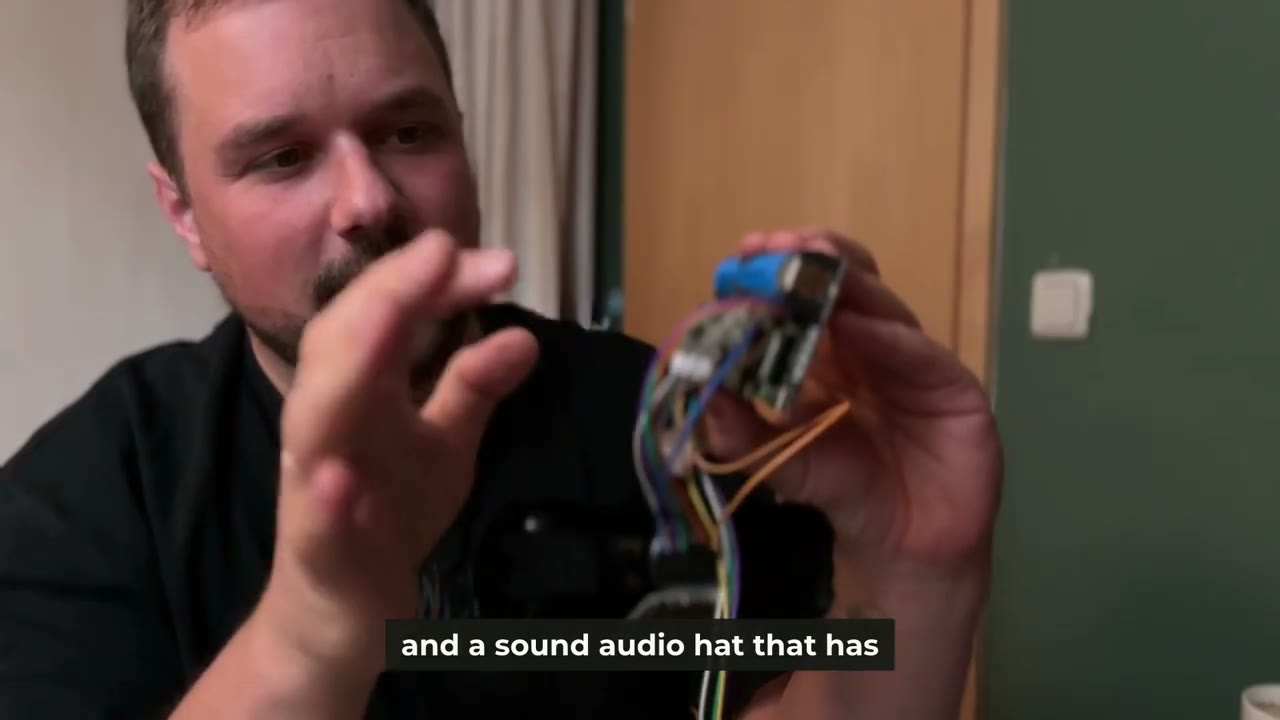
I want to see whether salvaged parts, inexpensive controllers, motors and this old phone can become a physical base. That’s the next experiment, not a finished robot. I’m sharing the steps as I work through them.
Filmed and presented by Lukas Timm. Original project footage and predominantly my recorded voice, with AI-assisted editing and short narration bridges using my own voice clone. The images on this page are frames from the published episode.
Watch episode 02 on YouTube ↗