
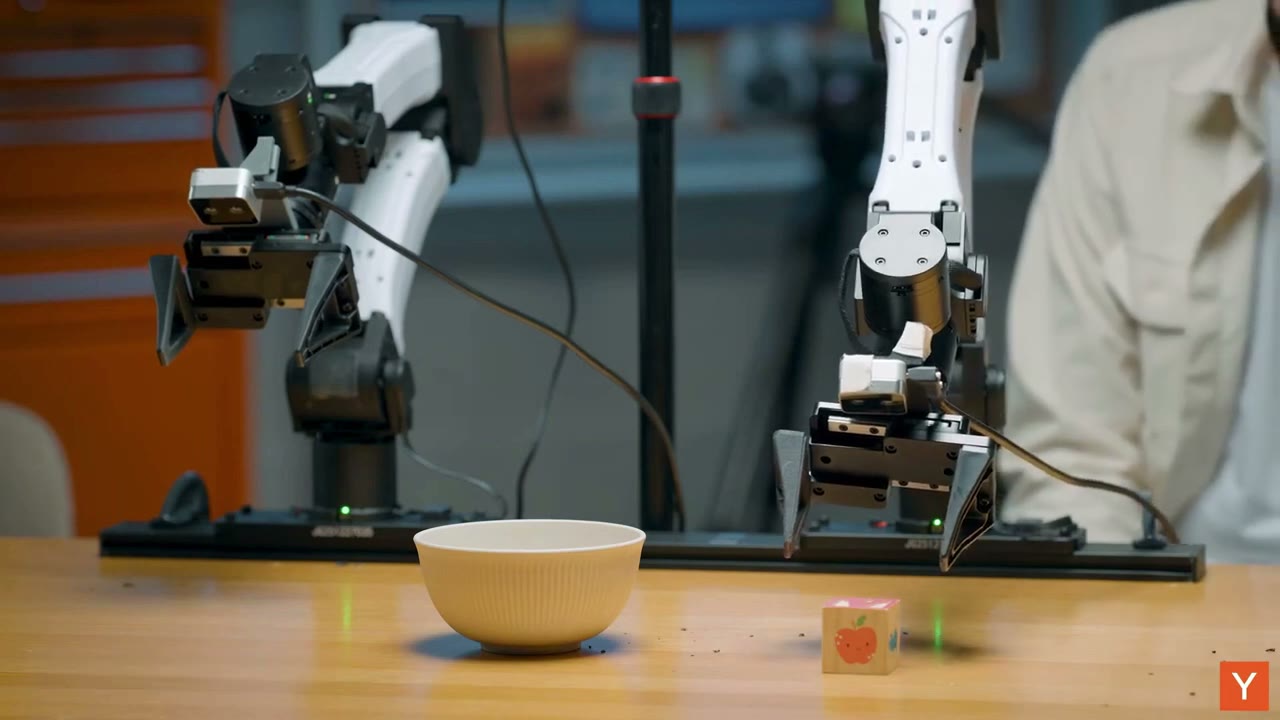
Mechanical engineering meets general-purpose AI controlling robot arms: a commentary on a source dual-arm pick-and-place demonstration, introducing the question of what actually works.
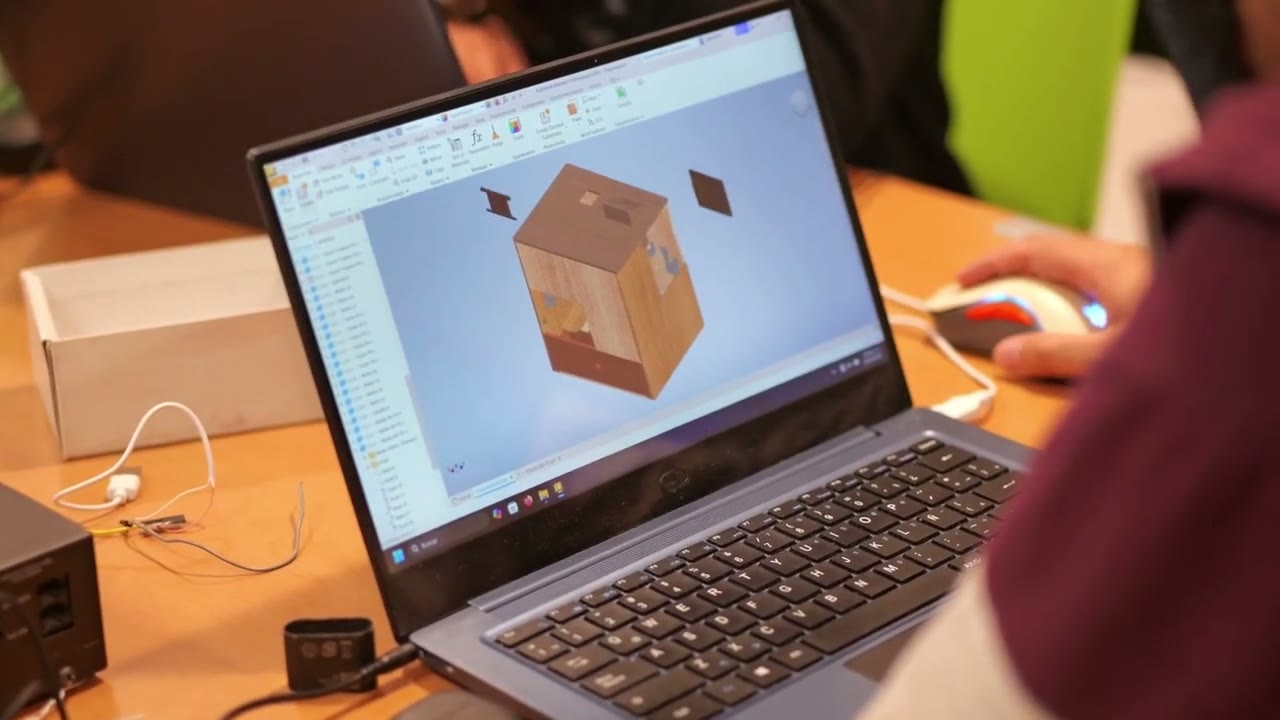
I trained as a mechanical engineer. The progression from pen-and-paper technical drawing to CAD was familiar. Watching a general-purpose AI system participate in a robot demonstration raised a different question: what changes when the software can act on the physical world?
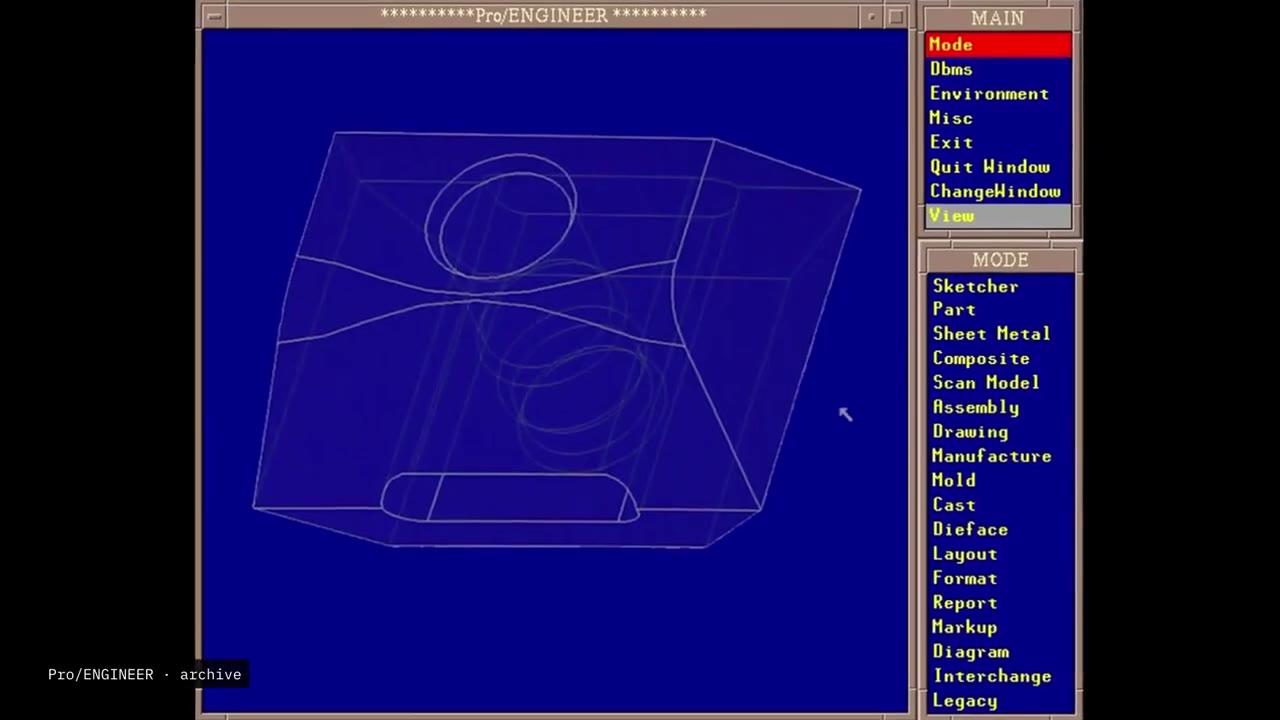
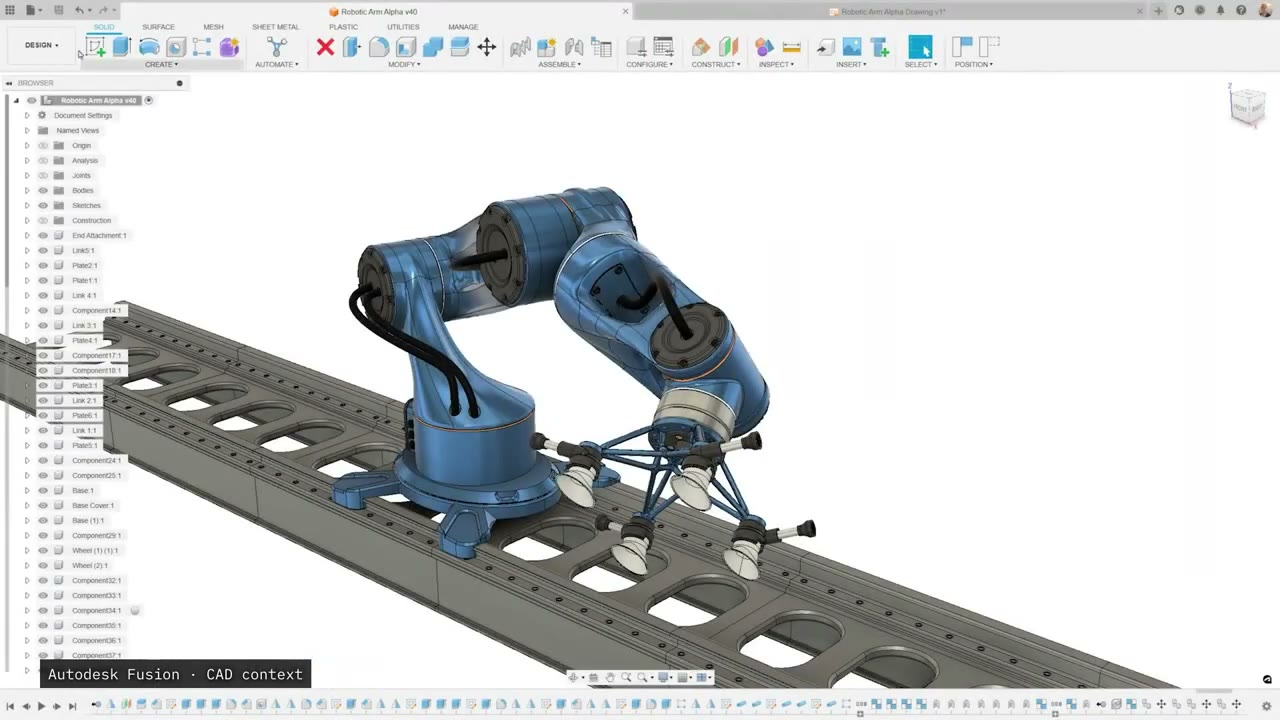
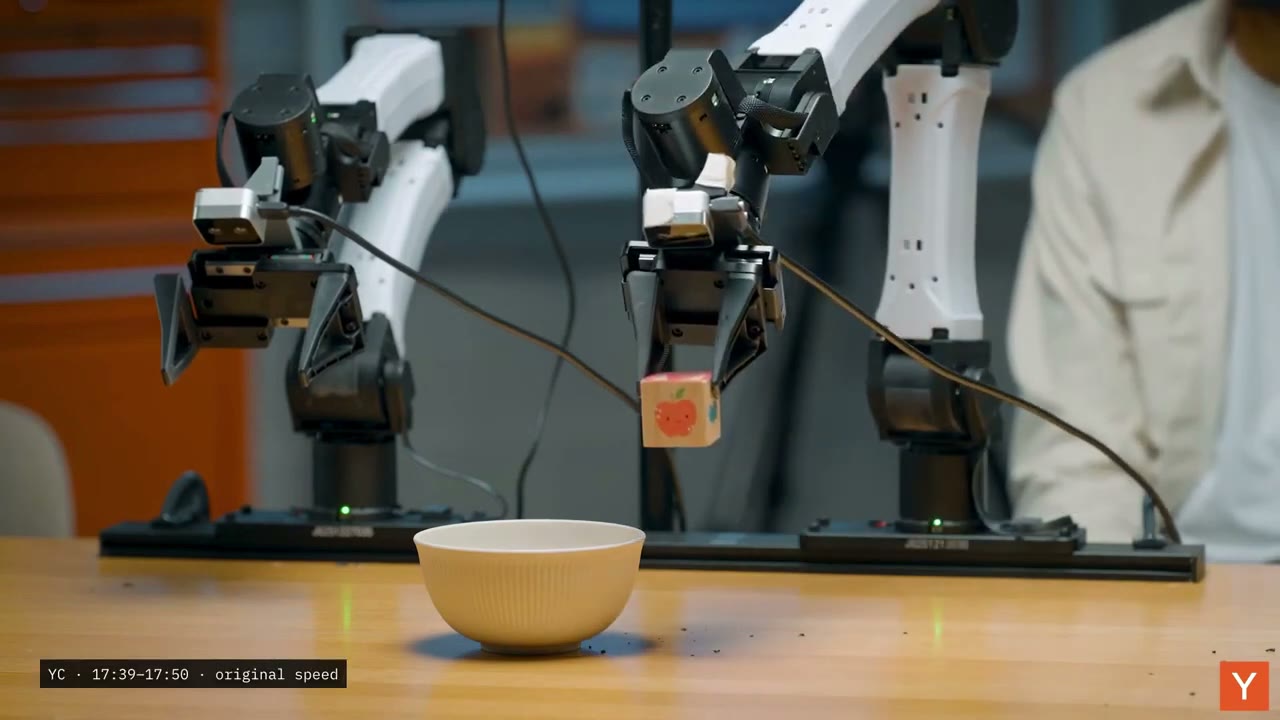
This episode begins with commentary on the Y Combinator interview and robot demonstration credited in the video. That demonstration belongs to its original source; it is not a test of my own hardware. My contribution is the engineering perspective and the decision to start trying things myself.
The useful next step was to build an experiment small enough to inspect. The rest of the series follows that move: from an impressive demonstration to my own room, sensors, simulations and eventually devices that can refuse to do what the code expects.
Read the detailed engineering field note →
Scope of this episode: Source robot demonstration, not Lukas hardware.
Based on the published episode and its production record. YouTube publication verified 22 October 2026. Stills are extracted from the released episode. Captions distinguish recorded evidence, reconstruction, simulation and illustrative material.