
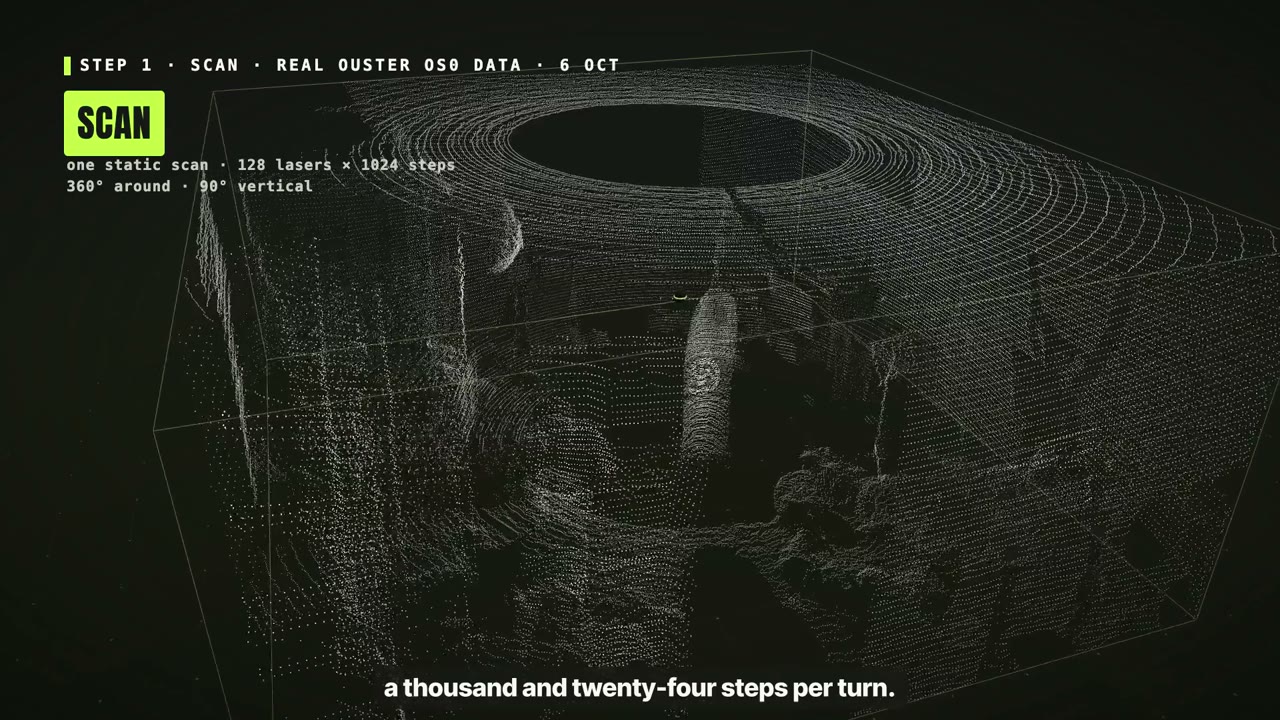
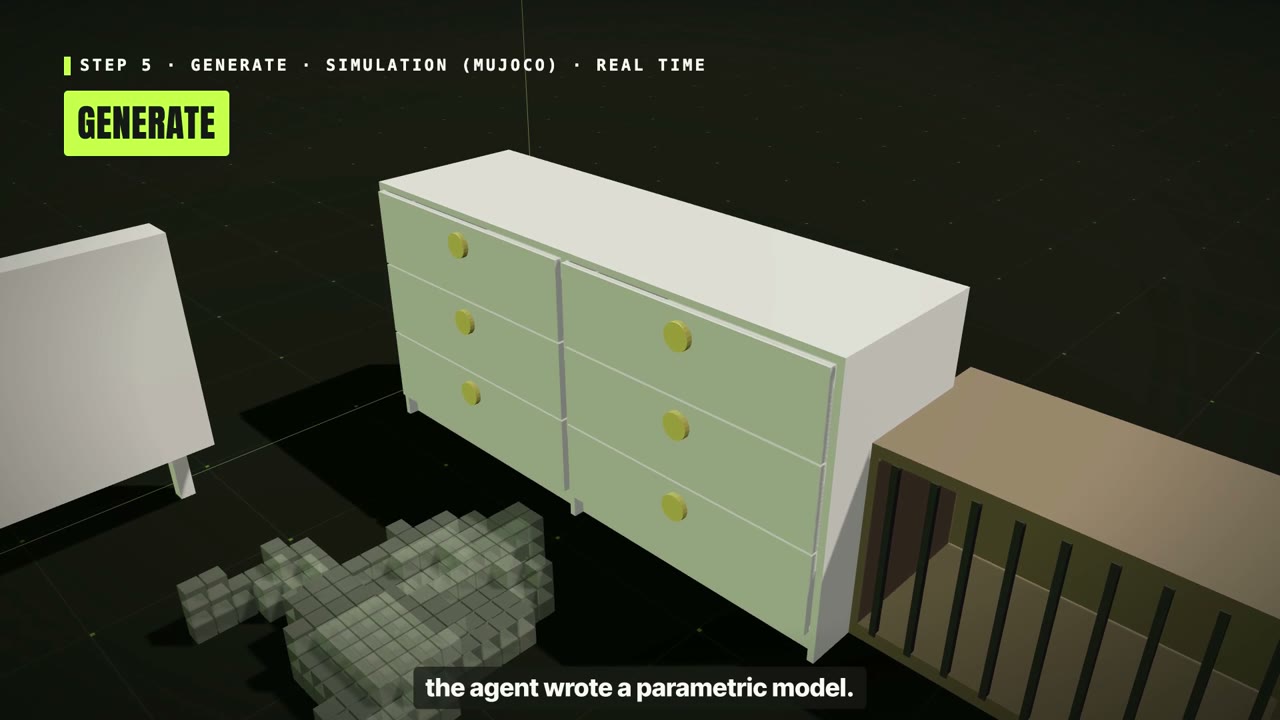
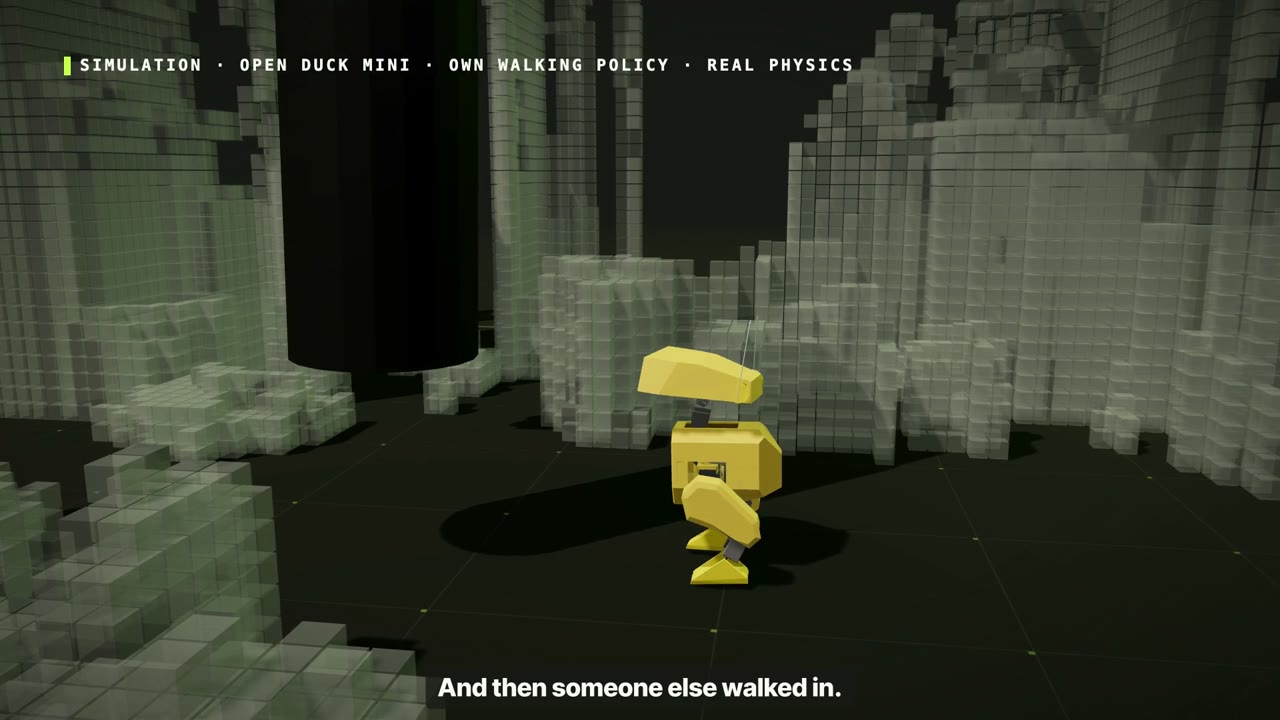
A real Ouster room scan and 13-second phone video become a simulated physical-AI dojo with splats, labelled objects, colliders and movable parts. Alignment and robot training infrastructure remain experimental; physical parameters are estimates.
The ambition was to turn my office into a repeatable place to try robot ideas. LiDAR and phone footage supplied different pieces of that environment: measured geometry and visual appearance.
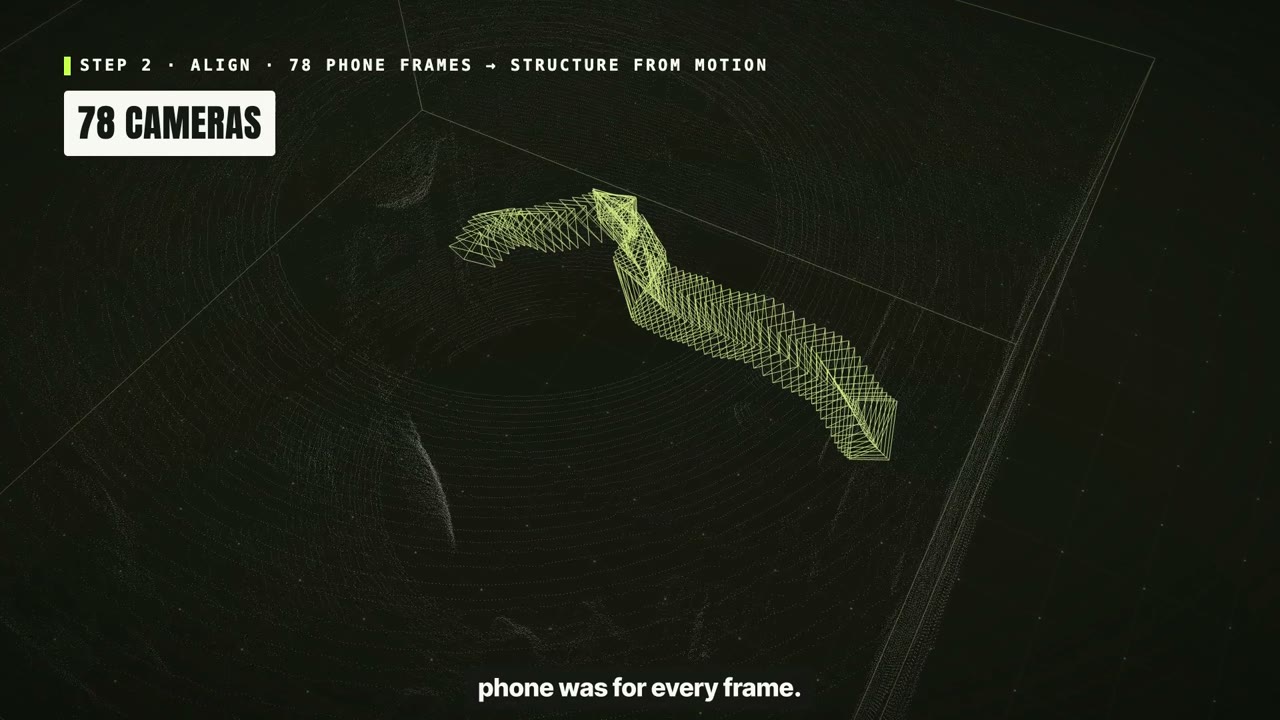
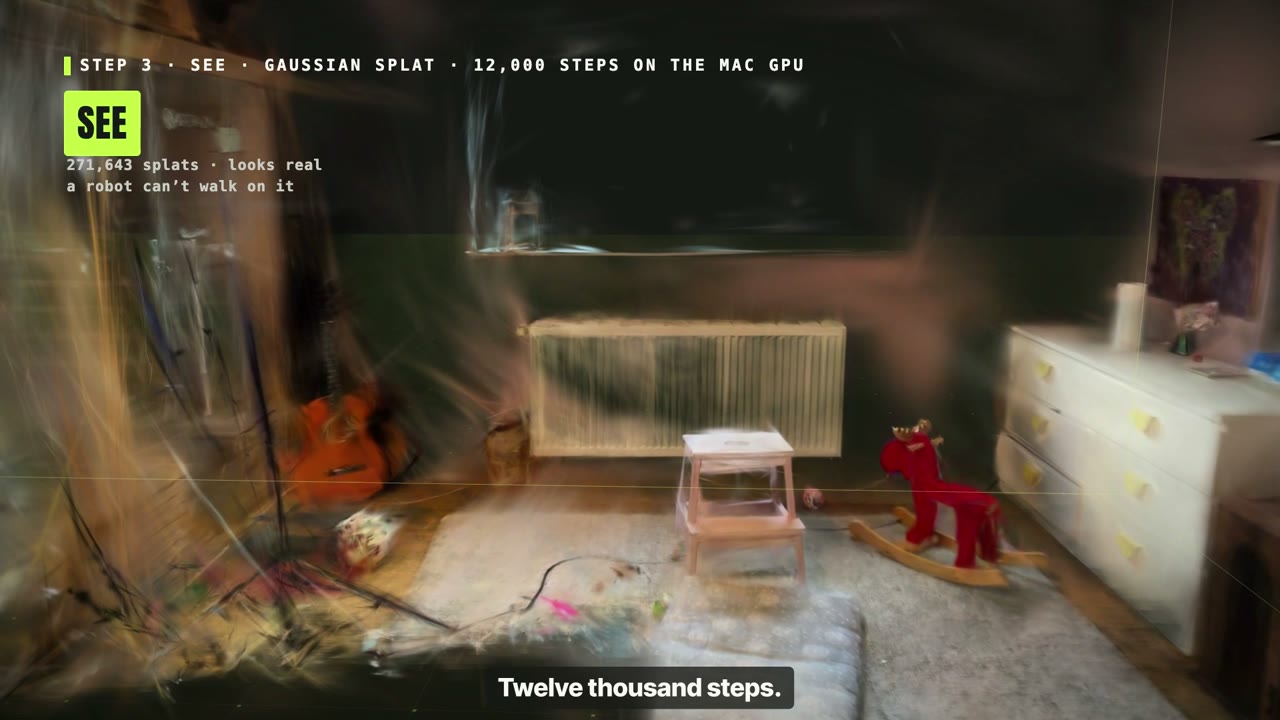
Reconstructing the room was only the beginning. An interactive twin needs usable spatial relationships and an environment where a simulated robot can act. It also needs a clear distinction between captured surfaces, reconstructed appearance and the objects introduced for the experiment.
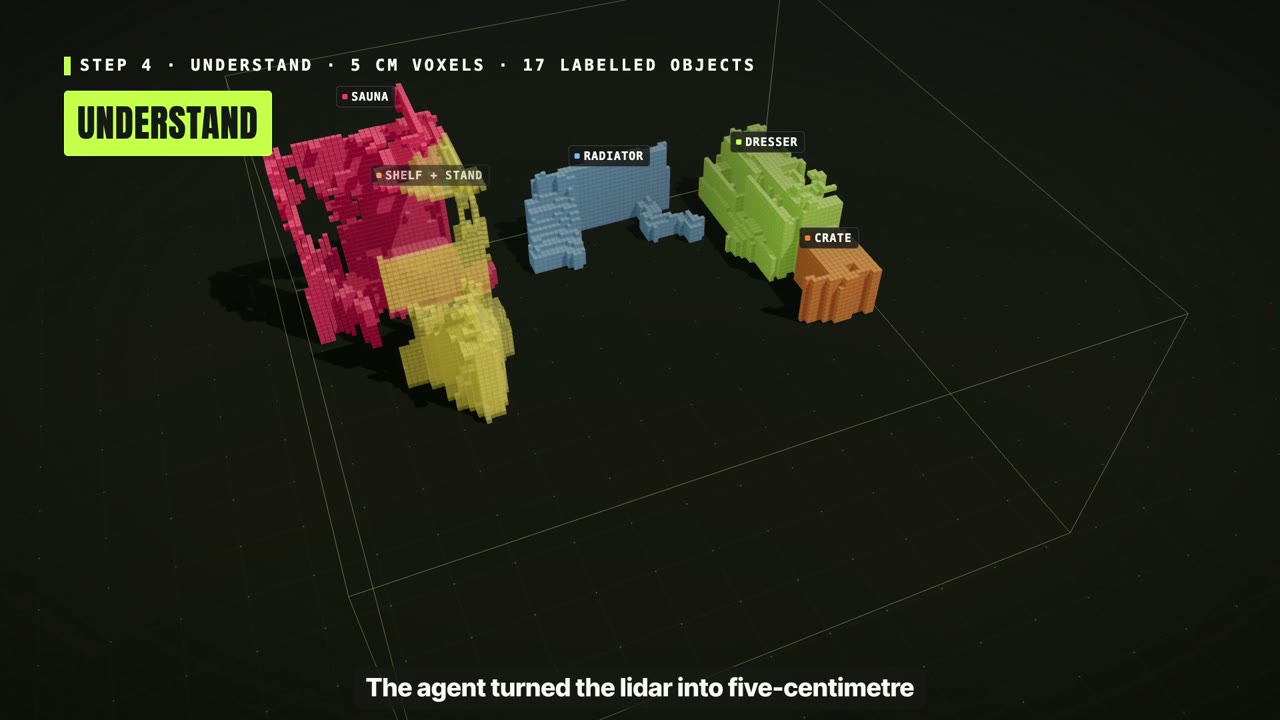
This is a mixture of real capture and simulation. A realistic room rendering does not itself validate collision geometry, metric accuracy or transfer to a physical robot. The next episode makes those assumptions harder to ignore by moving more robots into the scene.
Read the detailed engineering field note →
Scope of this episode: No trained autonomous real robot; masses estimated.
Based on the published episode and its production record. YouTube publication verified 22 October 2026. Stills are extracted from the released episode. Captions distinguish recorded evidence, reconstruction, simulation and illustrative material.