
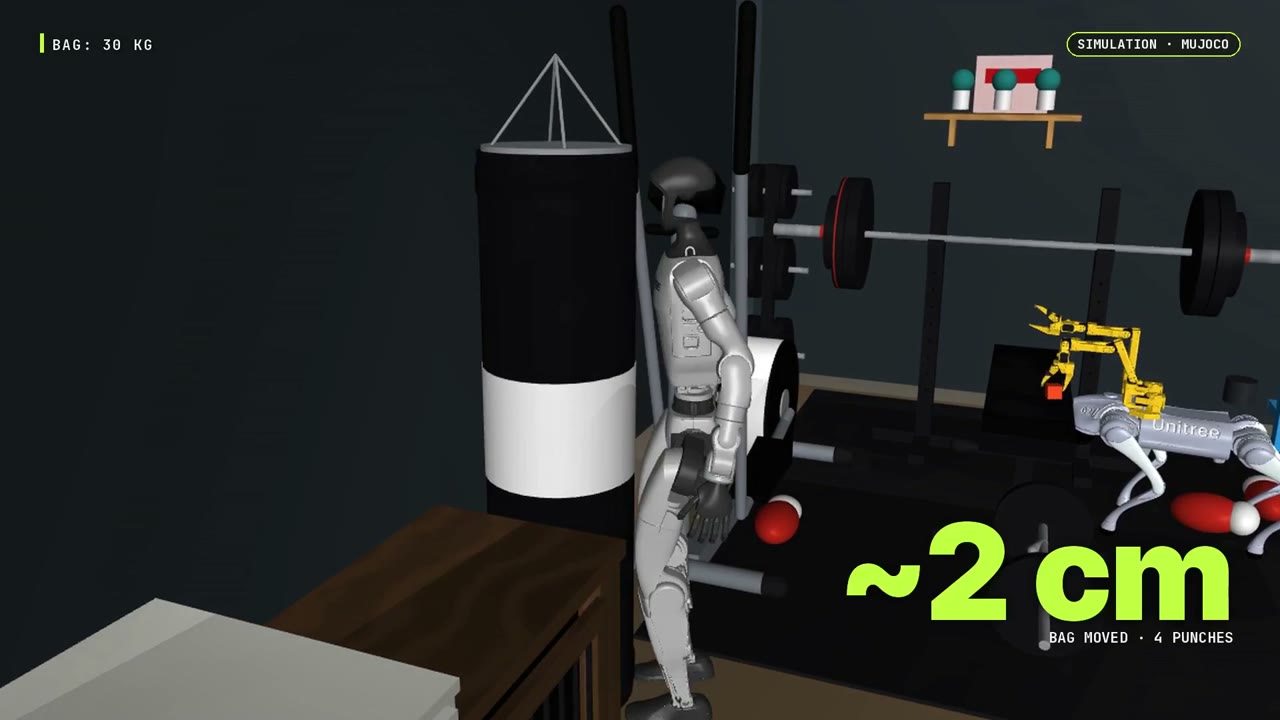
The office twin receives simulated Go2 and G1 robots. Calibration, movement, scene reconstruction, lighting and grasping failures precede a humanoid fall when the arm is forced overhead. All robot results are simulation.
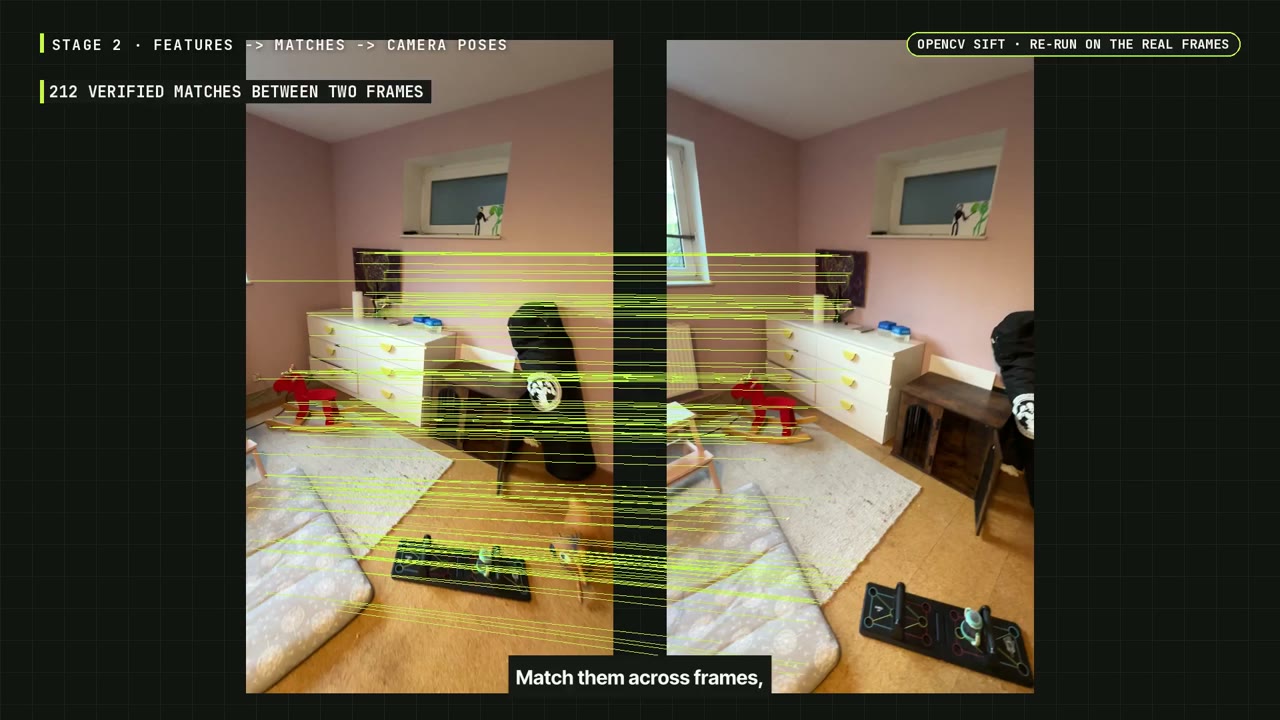
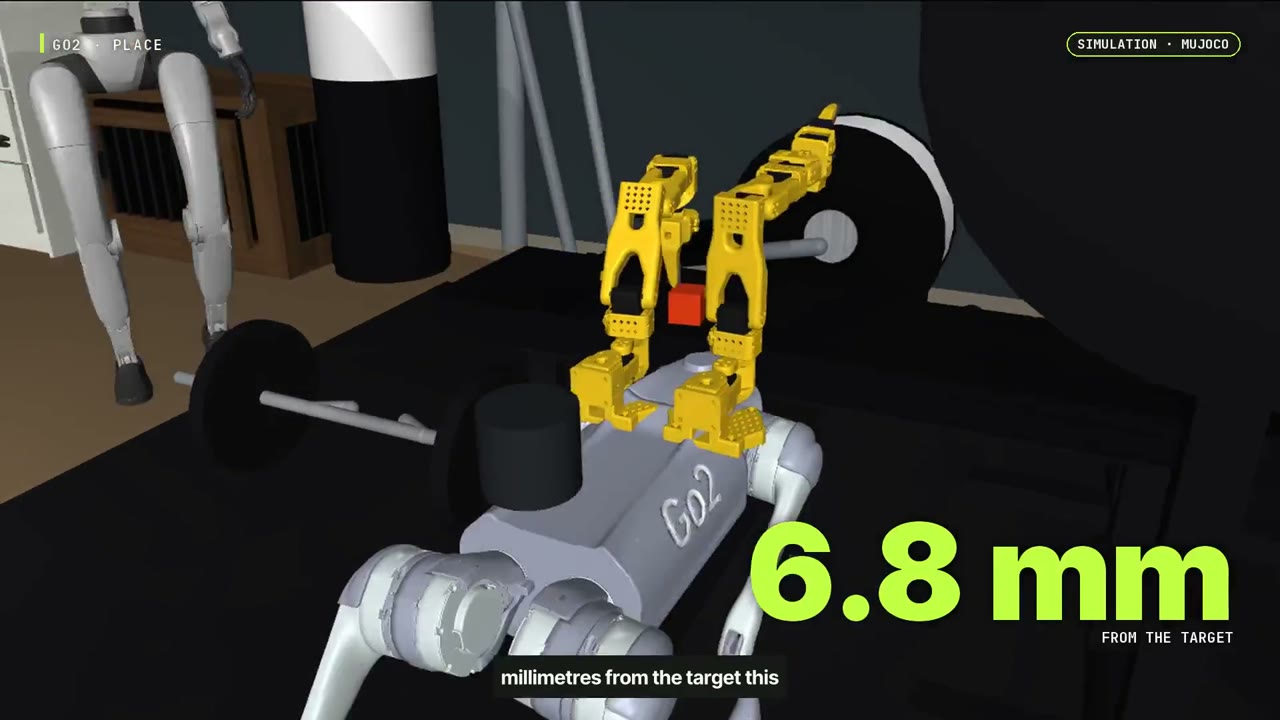
Go2 and G1 robots entered the office twin, and the experiment became a sequence of concrete problems: room alignment, crawling instead of walking, reconstructed geometry, lighting and a gripper closing on air.
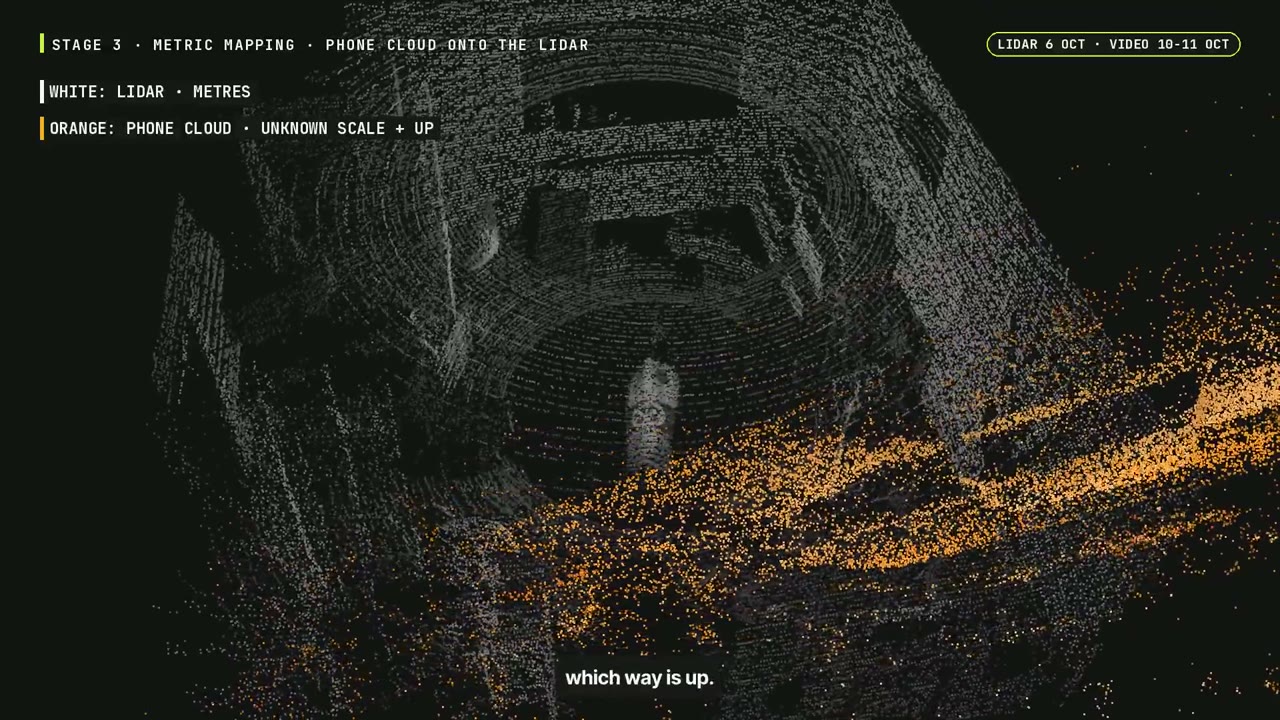
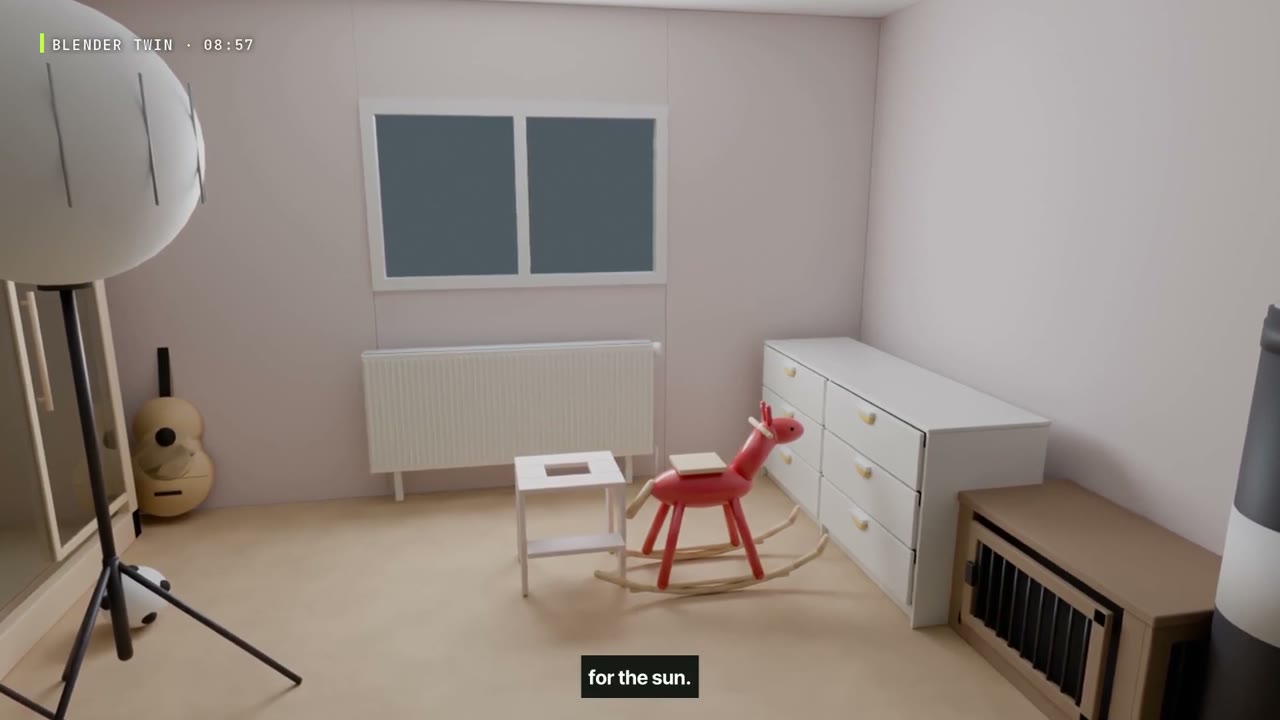
The Go2 manipulation attempt needed its own recovery work. The G1 could walk, but forcing an arm overhead exposed a balance failure. A capability that works in one motion does not automatically survive another.
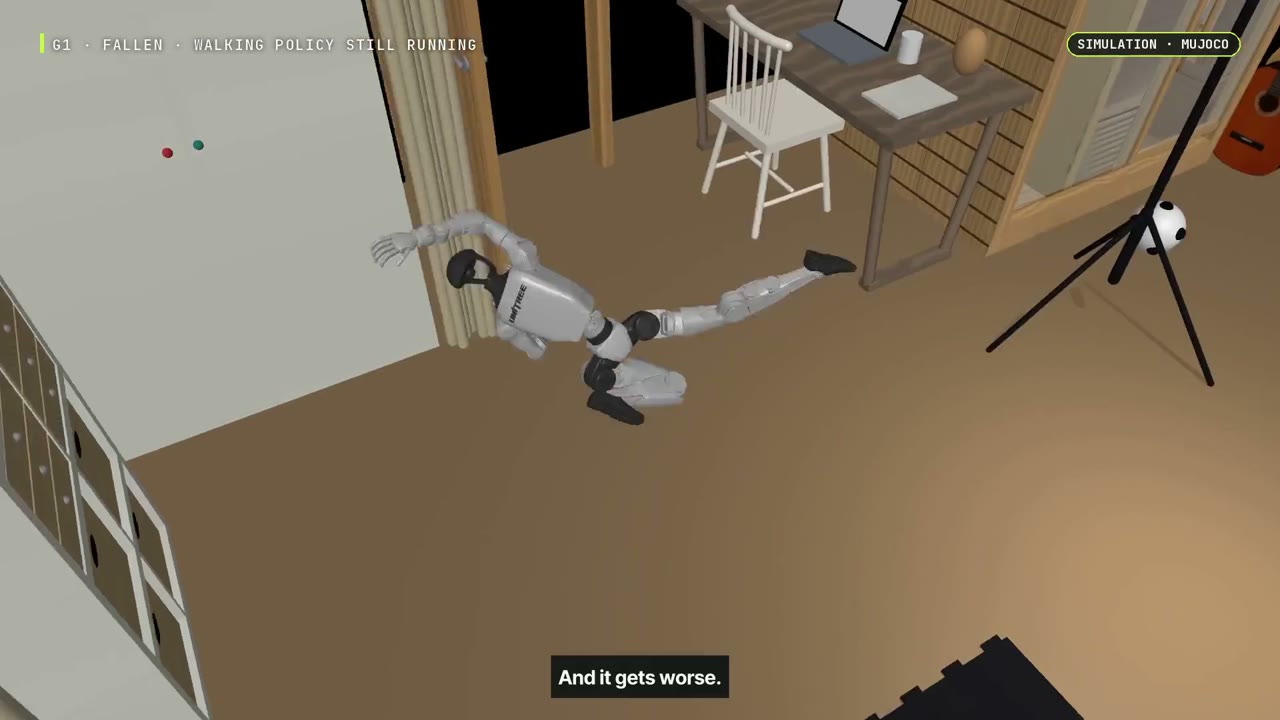
All robot-side evidence is simulated. The released G1 fall and fallen-robot drag were reconstructed with an open velocity policy and model, not recovered as footage of the original run. The result is a useful account of integration and failure, with grasp repeatability and physical deployment still unresolved.
Read the detailed engineering field note →
Scope of this episode: All robot-side evidence simulated; grasp repeatability unresolved.
Based on the published episode and its production record. YouTube publication verified 22 October 2026. Stills are extracted from the released episode. Captions distinguish recorded evidence, reconstruction, simulation and illustrative material.