EP06 / THE PLATFORM
Understand the arm.
Manufacturer CAD and robot descriptions make the joint layout, proposed sensor setup and control interface inspectable.
 Book a call ↗
REALMAN ECO65 / CROSS-EPISODE CASE STUDY
Independent editorial examples. These projects were not paid for by, sponsored by or affiliated with the featured manufacturers. They illustrate the format of a possible collaboration, not an existing client relationship.
The ECO65 starts as a manufacturer-derived digital twin, becomes Gemini’s simulated basketball arm, and then inspires Heron’s neck and beak. Each experiment changes what I need to understand before building the physical system.
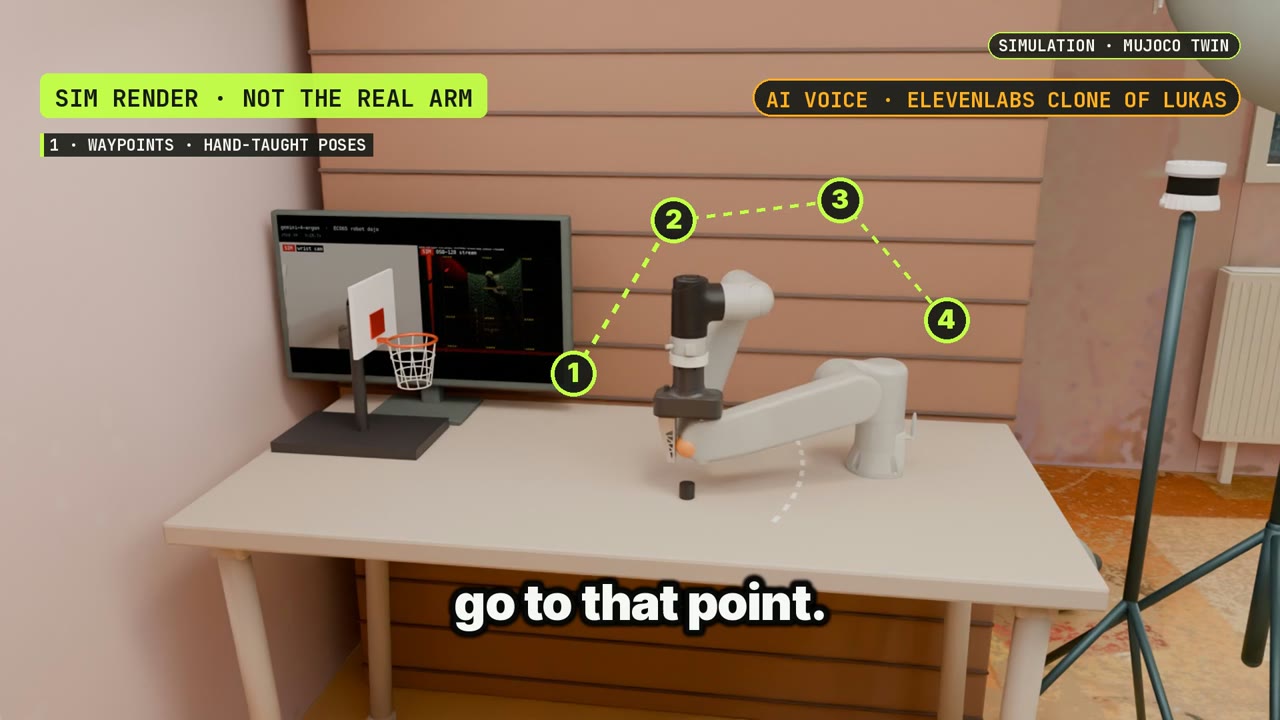
EP06 / THE PLATFORM
Manufacturer CAD and robot descriptions make the joint layout, proposed sensor setup and control interface inspectable.
EP11 / A CONCRETE TASK
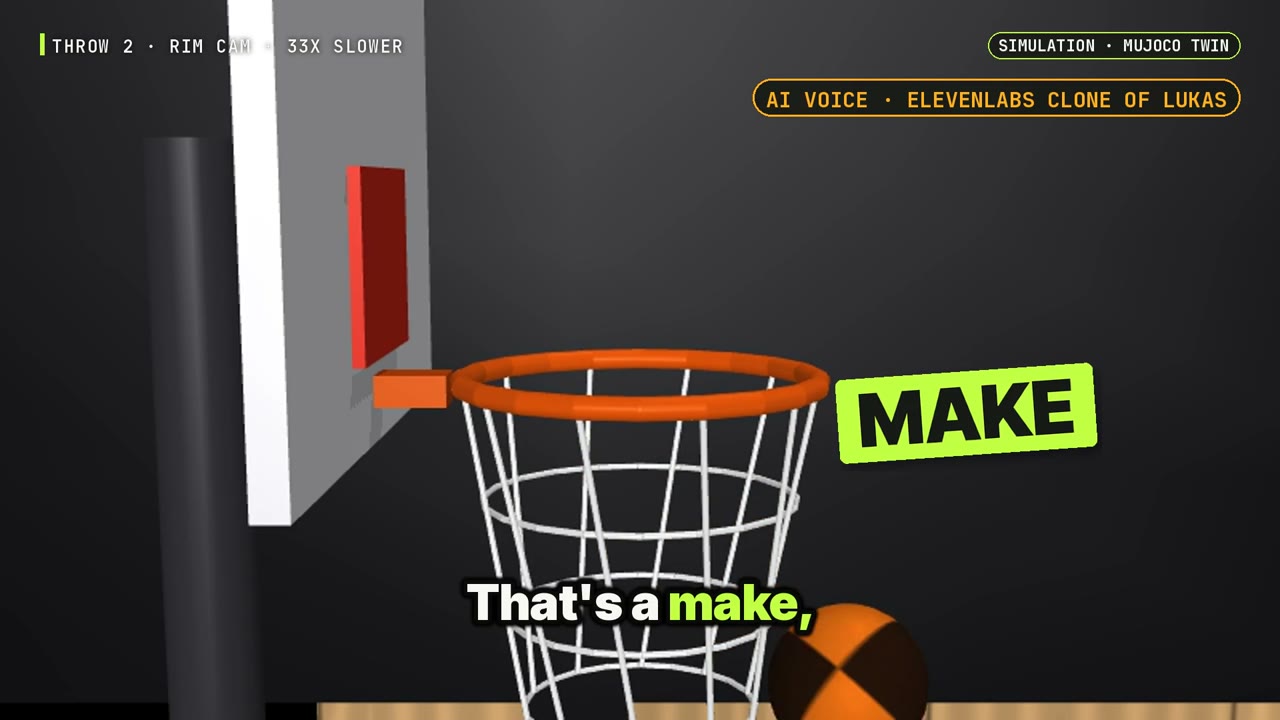
Four baskets in five simulated throws; Gemini calls one made basket a miss. Action and outcome recognition need separate checks.
HERON / A NEW BODY
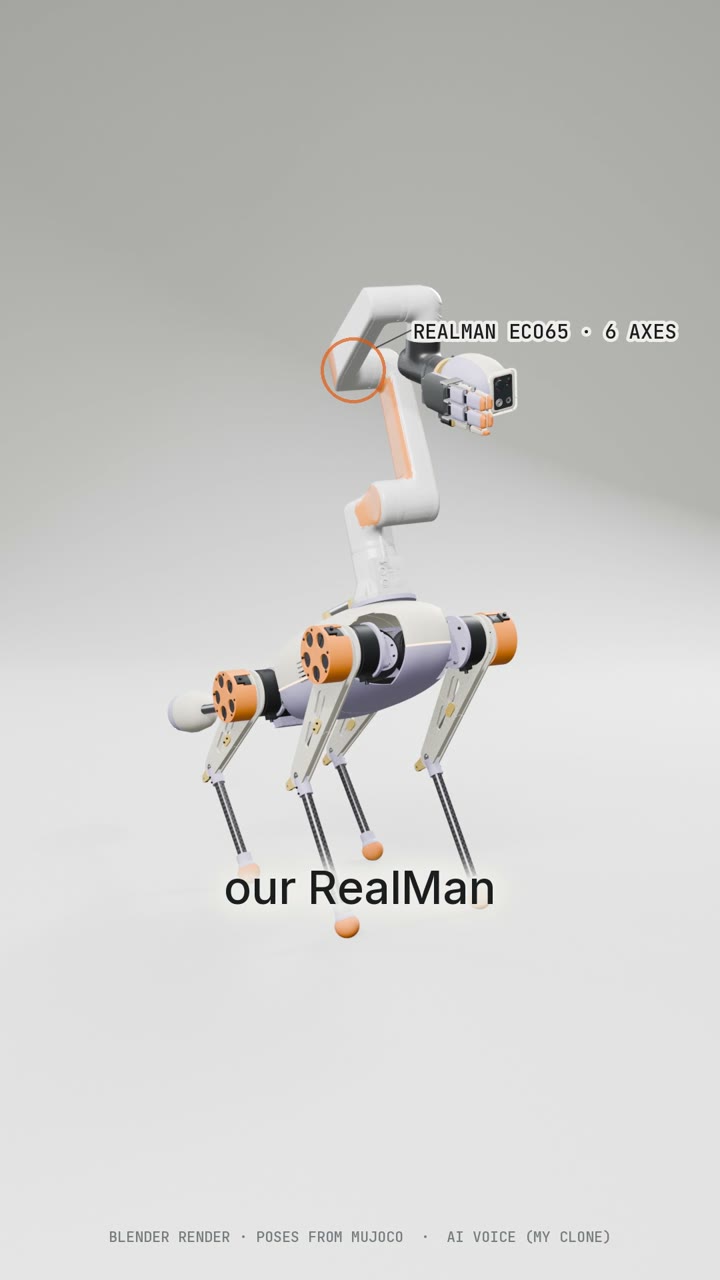
The ECO65 replaces the separate-arm layout in a new robot concept. Reach, hand design and mass become coupled questions.
CROSS-EPISODE FIELD NOTES · UPDATED 22 OCTOBER 2026
The first ECO65 episode asked what an AI agent might do with an arm, LiDAR and two cameras. The later work gave that broad question a specific task, then changed the body around the arm altogether. The common thread is making the assumptions visible before treating the model as a physical result.
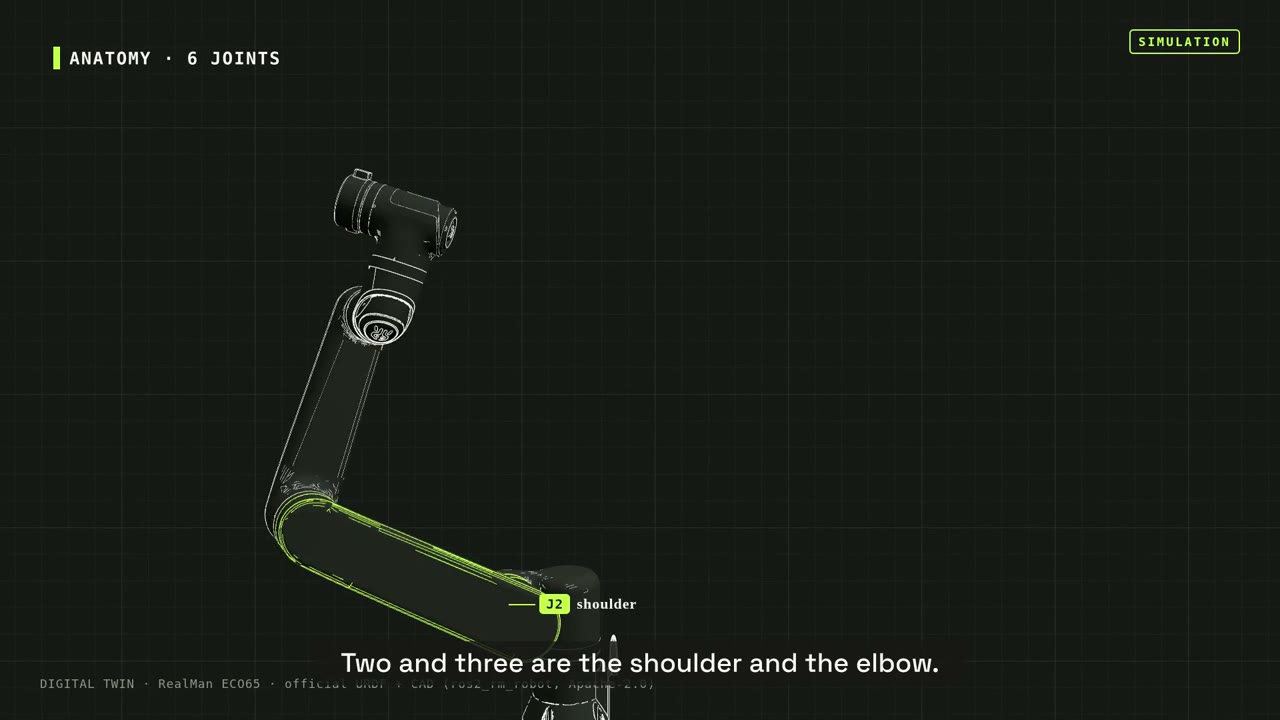
In Episode 6, I used manufacturer CAD and robot-description files to explore the arm’s anatomy, the planned sensors and the interfaces a control loop would need. The useful result was a concrete starting point for bring-up: which joints move, what the camera could see, and how a target pose might become motion.
The physical arm had not arrived for that experiment. The episode’s title asks about a real robot arm, but the demonstrated arm sequences are simulation. This distinction becomes important when the following experiment starts producing scores.
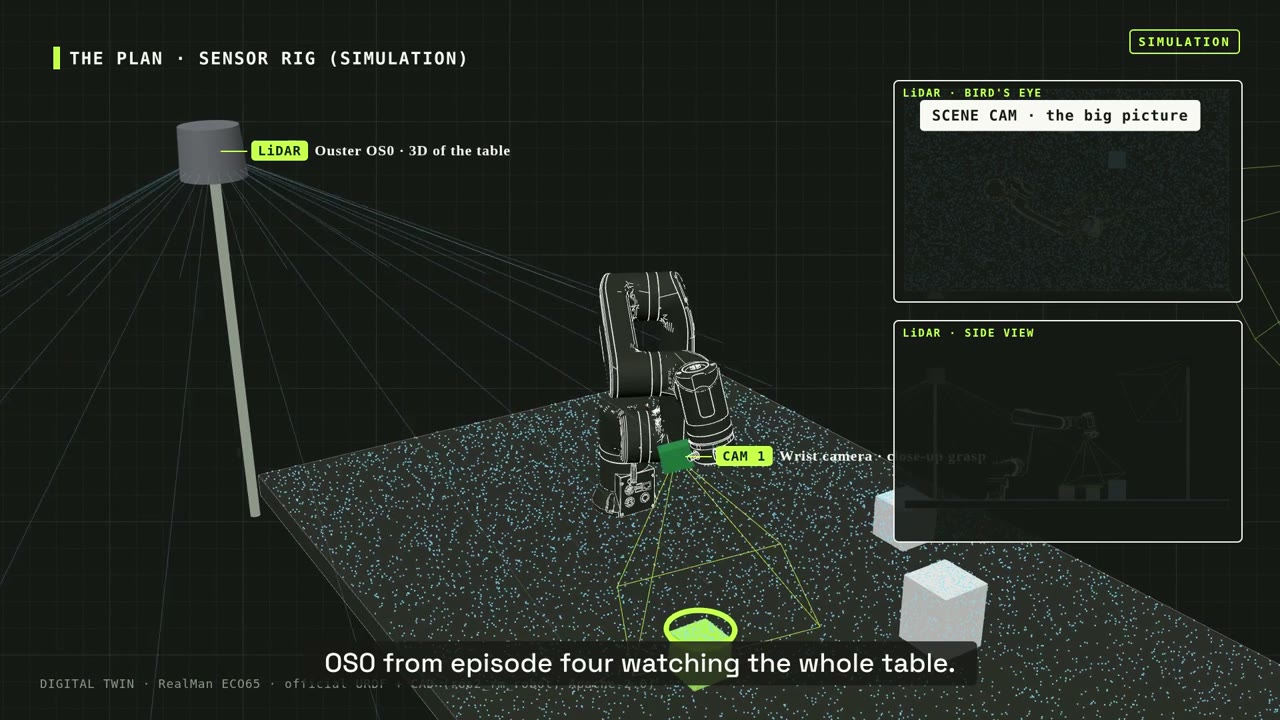
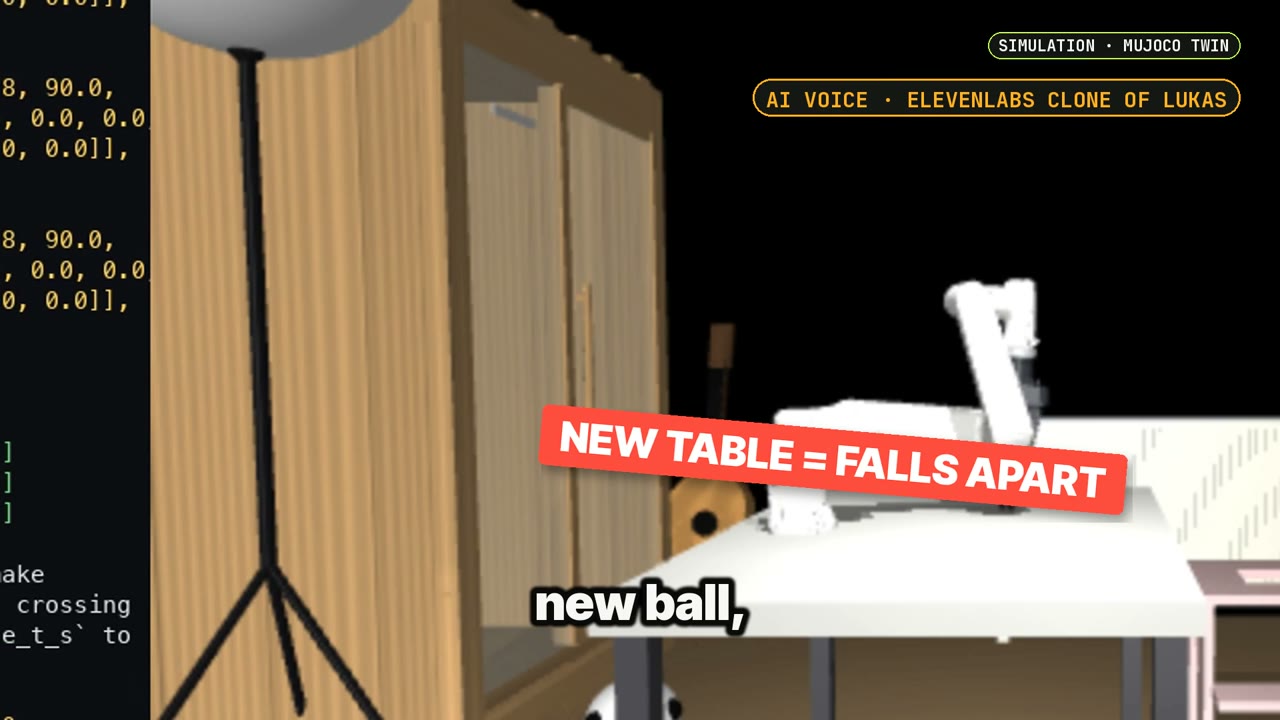
In Episode 11, Gemini received camera views, LiDAR and code-writing access to the simulated ECO65 in the desk twin. It did not receive the hidden ball coordinates or the simulator’s score. Before the throws could mean much, we had to correct the table, fix an unstable simulation and stop the gripper squeezing the foam ball out.
The final five-throw run made four baskets, after roughly 26 minutes of model thinking. Then came the more useful surprise: Gemini labelled one made basket as a miss. The simulator’s independent score exposed an error that a convincing movement alone would not reveal.
That changes the bring-up question. It is not enough to ask whether an agent can produce a trajectory. Can it tell whether the action worked, and decide whether to retry? Five throws in one fixed simulated scene answer a small part of that question. They do not establish physical throwing performance or a general robotics benchmark.
The Heron design experiment takes the ECO65 in a different direction. Instead of two separate small arms on a quadruped, the concept uses the ECO65 as a neck and puts a tactile beak-hand at its end. Observation and manipulation move together, but the arm’s weight now affects the whole walking body.
The design estimate rose from roughly 16.2 kg for an earlier layout to about 22 kg for the arm-neck concept. A discrepancy between listed arm mass and summed URDF link masses is still part of the modelling discussion. The latest hand also changes the load. The film’s earlier support-margin estimate should not be read as a current stability test.
The beak’s four fingers and swivelling thumb use six proposed actuators. Mug and egg grasps use MuJoCo contact and tactile feedback; their displayed forces are simulated. The Mini-X eye links this body concept back to the RGB + depth work. Neither the integrated head nor the complete walking Heron has been validated as physical hardware.
The basketball experiment points to camera timing, gripper contact and independent outcome checks. Heron adds mass, balance and continuous motor loading. A physical bring-up needs to measure those assumptions, rather than inherit the simulation’s apparent success.
 Watch episode 06 ↗
Robot hardware not yet present; plan and simulation.
Read the episode field note → Watch episode 11 ↗
Five throws in fixed simulation, not robotics benchmark or physical test.
Read the episode field note →HOW THIS COULD WORK FOR YOUR TEAM
For a robot provider, this format can become a platform introduction, setup tutorial and application-led demo, with separately agreed sponsored distribution.
Explore the offer→Pricing on request
LET’S BUILD A USEFUL STORY
Bring a product, a workflow or an engineering question. We agree the experiment, deliverables, publication and usage before the work starts.
Discuss a collaboration↗Pricing on request · lukas@alphavant.com