
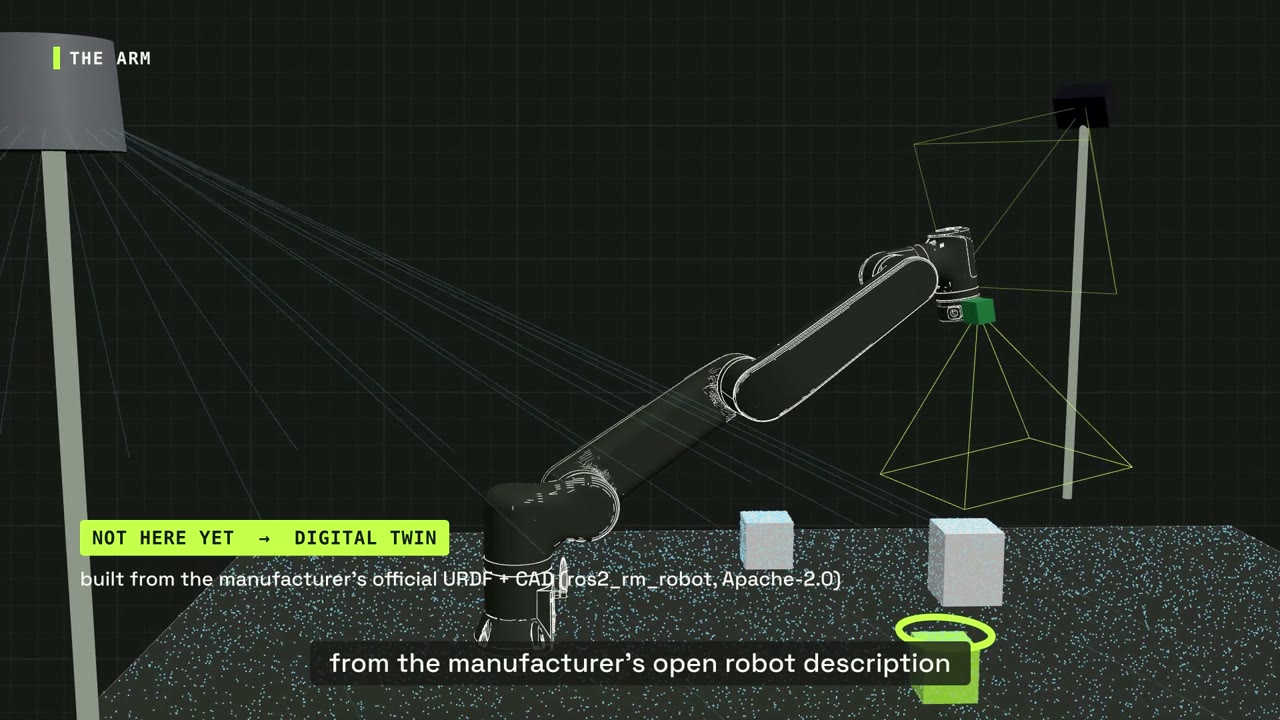
The planned RealMan ECO65 setup is explored using manufacturer CAD and robot description: cameras, LiDAR, interfaces and a target-pose control loop. The hardware has not yet arrived; all arm sequences are simulation.
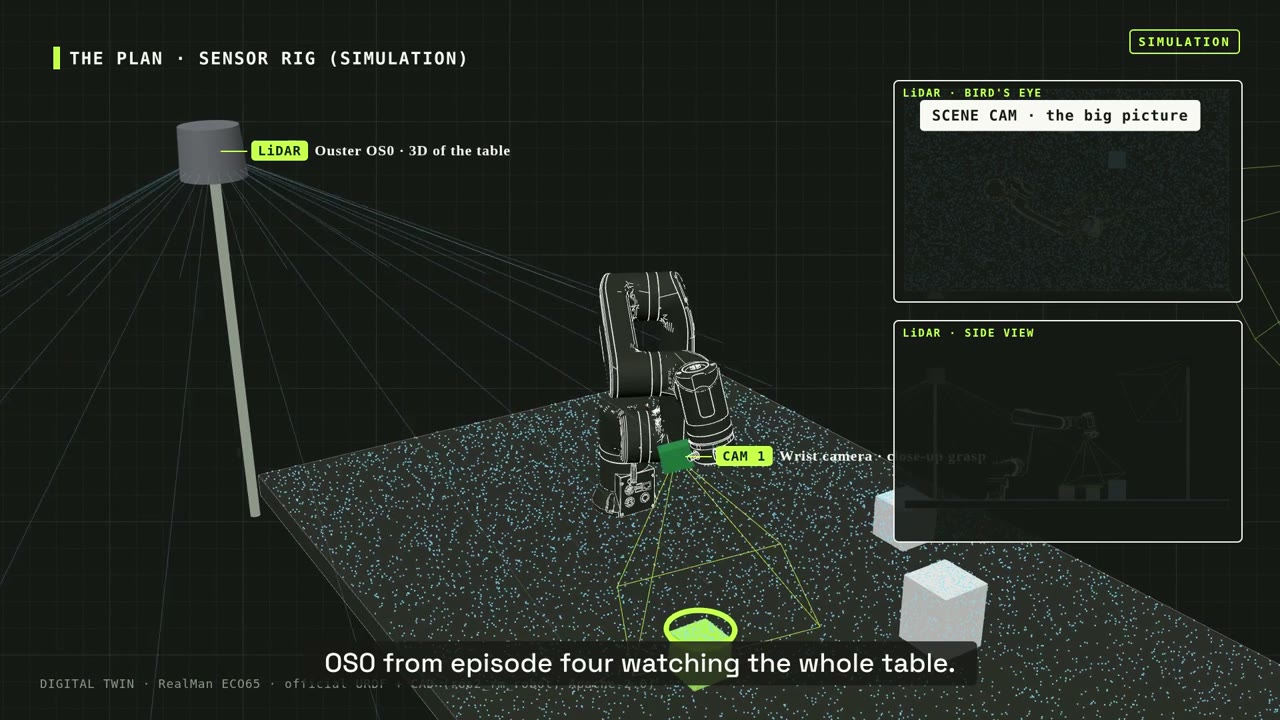
A RealMan ECO65 was due to arrive on loan. Before touching the physical arm, I used the manufacturer’s robot description and CAD to understand the digital twin: the joints, reach, interfaces and tool mounting.
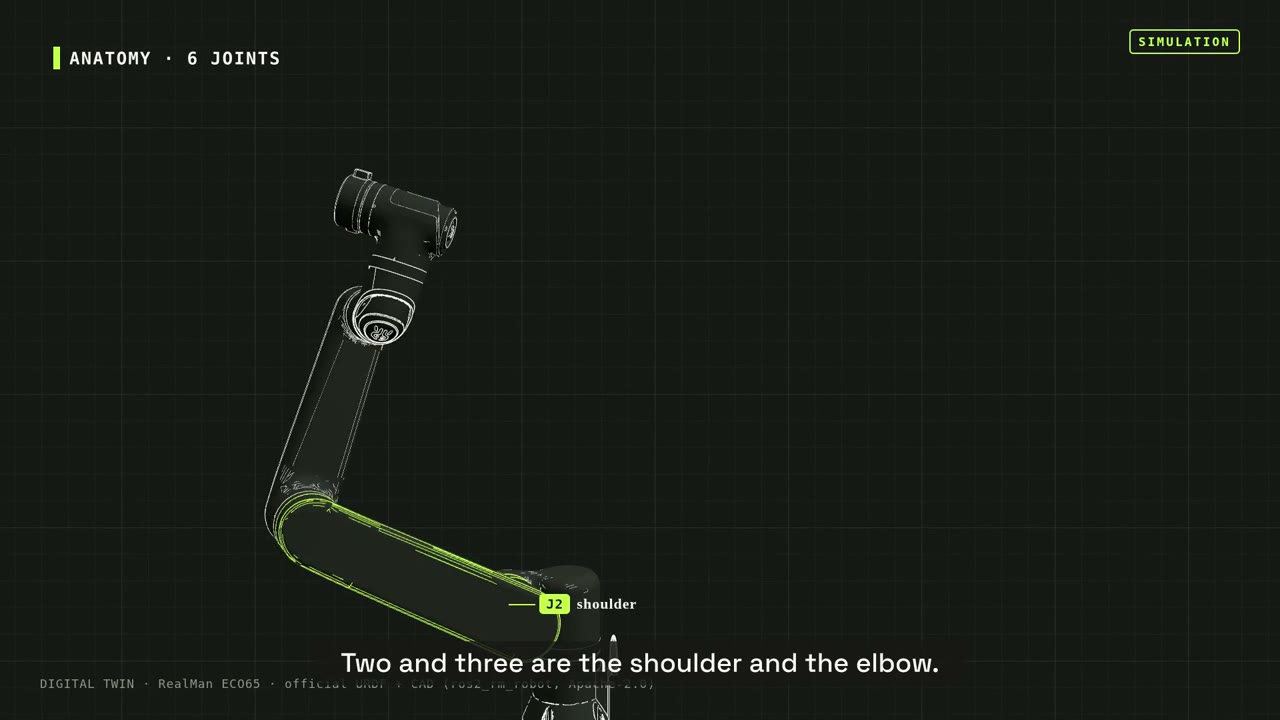
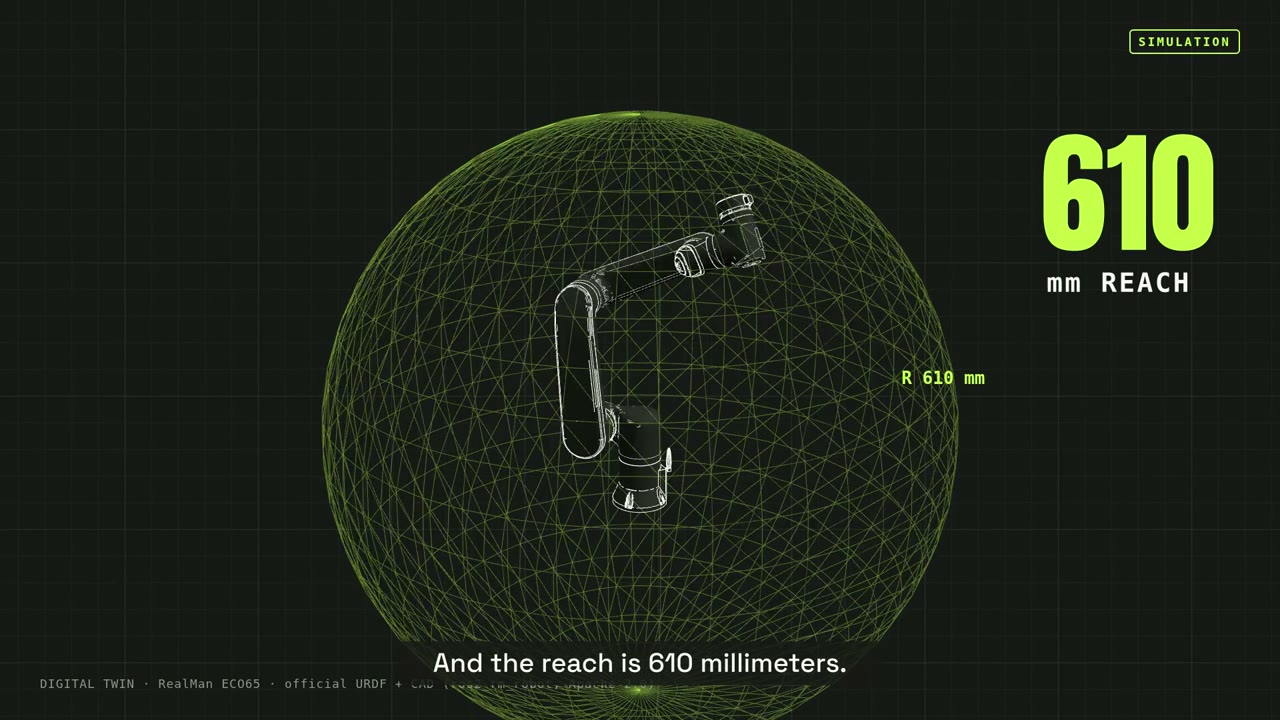
The proposed observation stack combined a wrist camera, a scene camera and the Ouster OS0. The control idea was to let an agent reason about target poses while a separate layer checked workspace and speed limits. That was the intended architecture, not proof of safe autonomous operation.
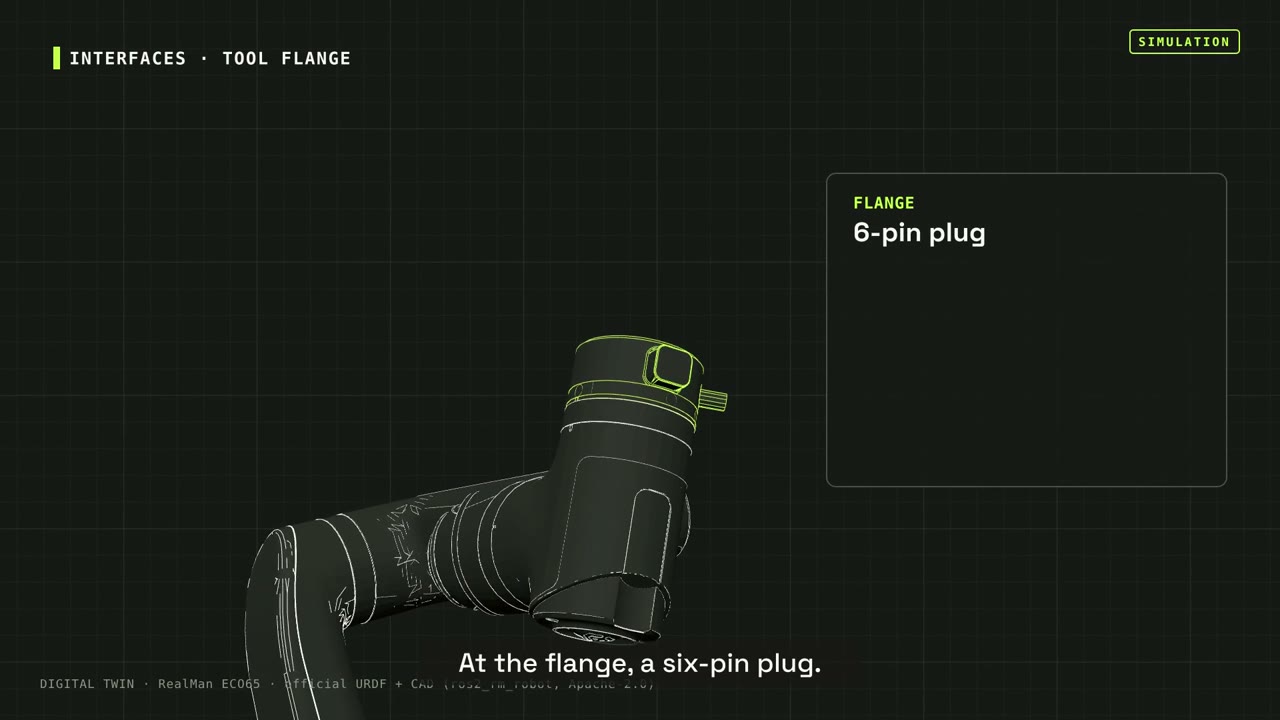
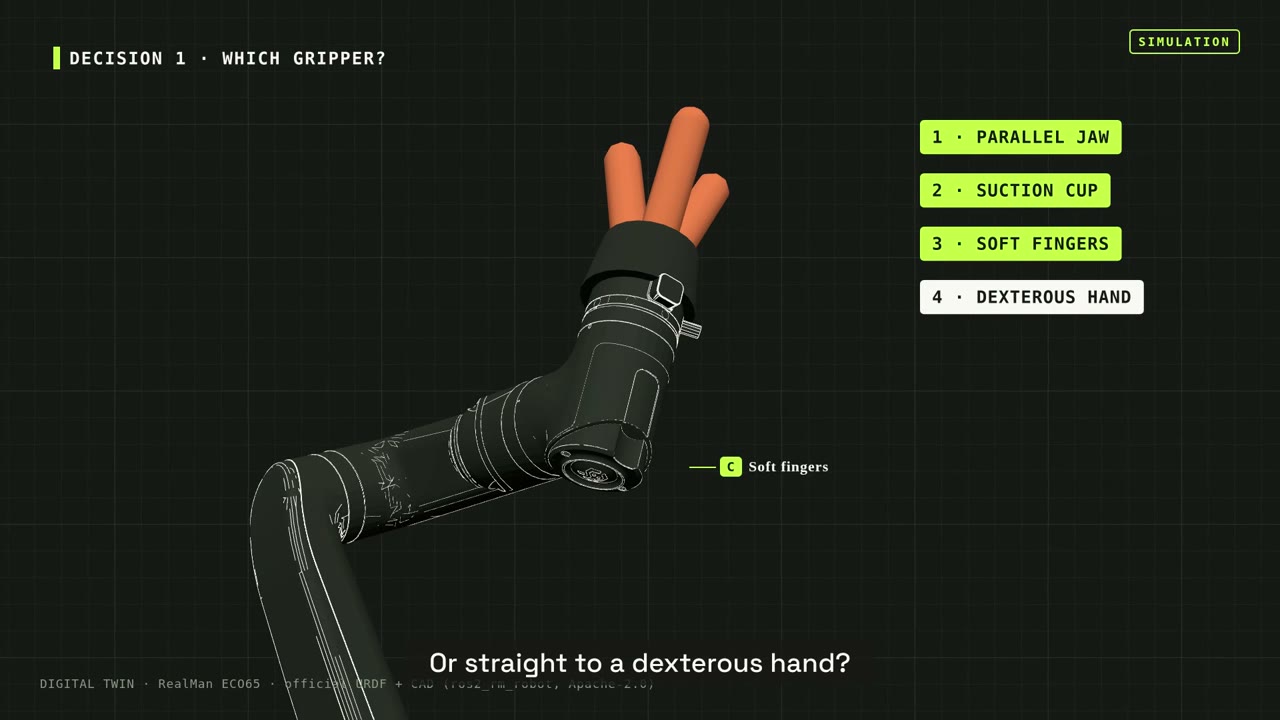
This episode is preparation in simulation. It does not show the real arm executing the plan. Choosing a gripper and deciding between the SDK, ROS 2 and an agent-facing control interface remained part of the build discussion.
Read the detailed engineering field note →
Scope of this episode: Robot hardware not yet present; plan and simulation.
Based on the published episode and its production record. YouTube publication verified 22 October 2026. Stills are extracted from the released episode. Captions distinguish recorded evidence, reconstruction, simulation and illustrative material.