
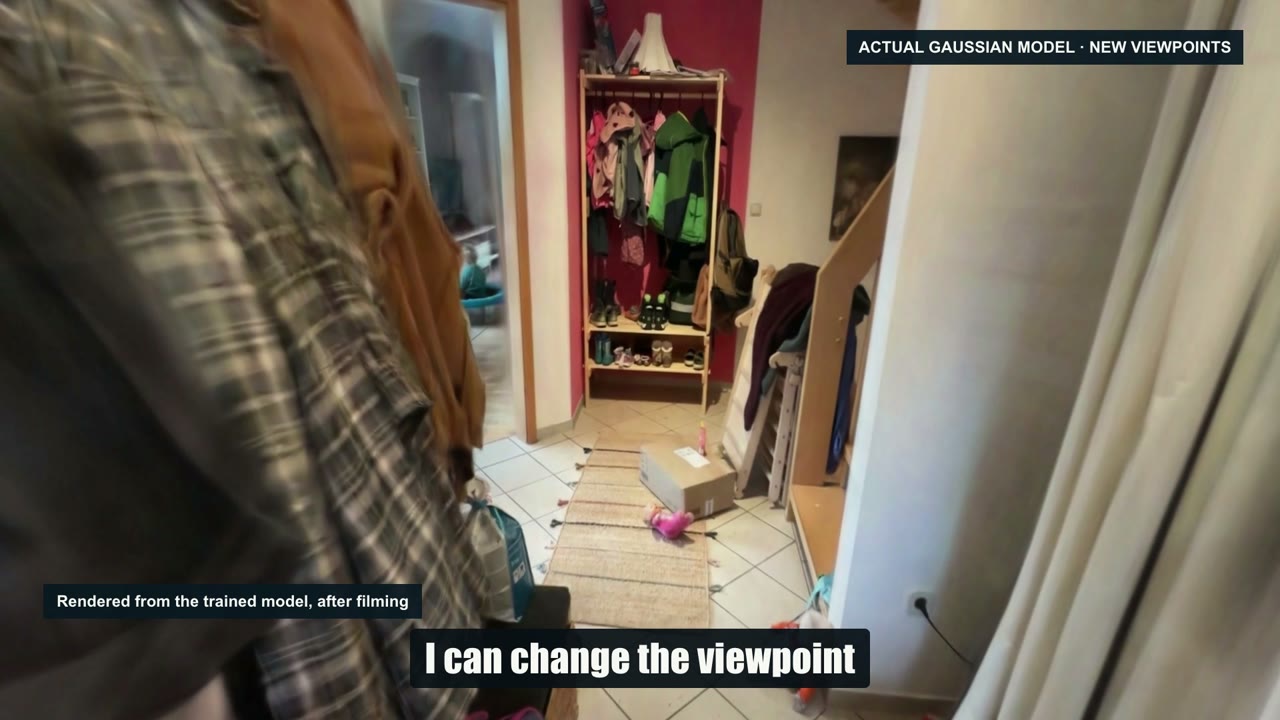
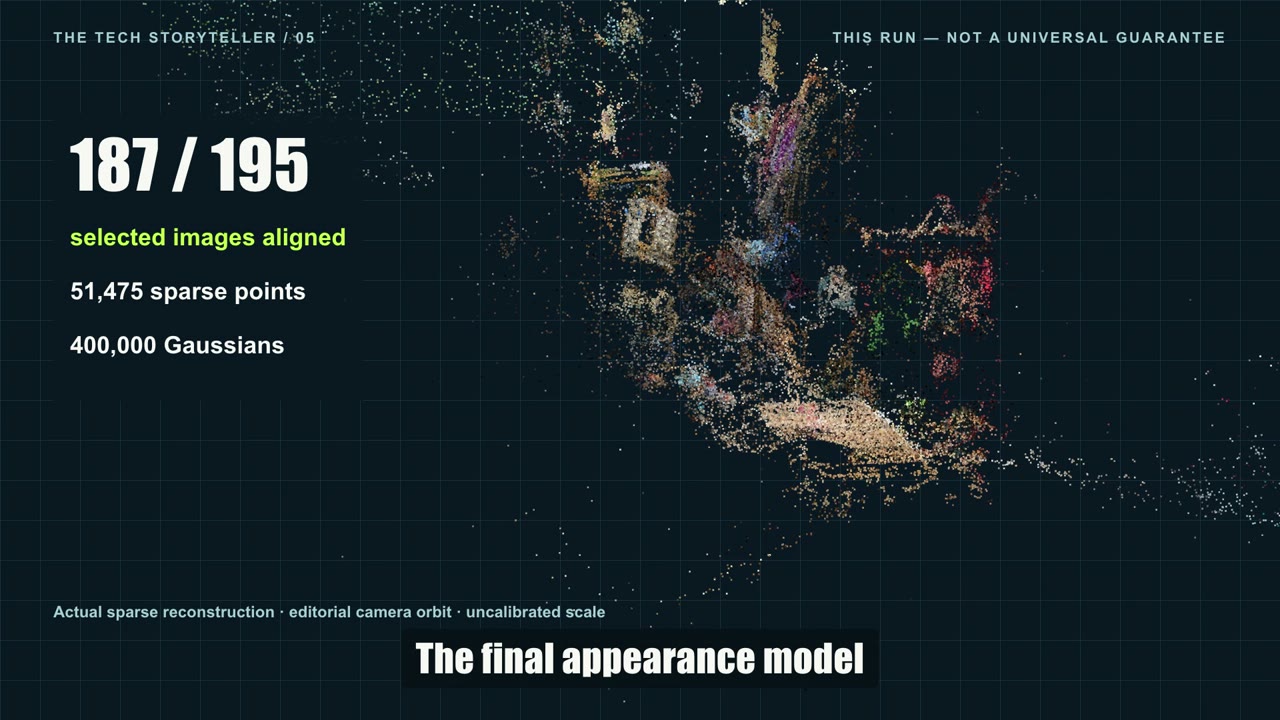
A 48.6-second phone video produces a room reconstruction without LiDAR input: 187/195 selected images align, 51,475 sparse points and 400,000 Gaussians. Appearance works, while metric scale and unseen surfaces remain unverified.
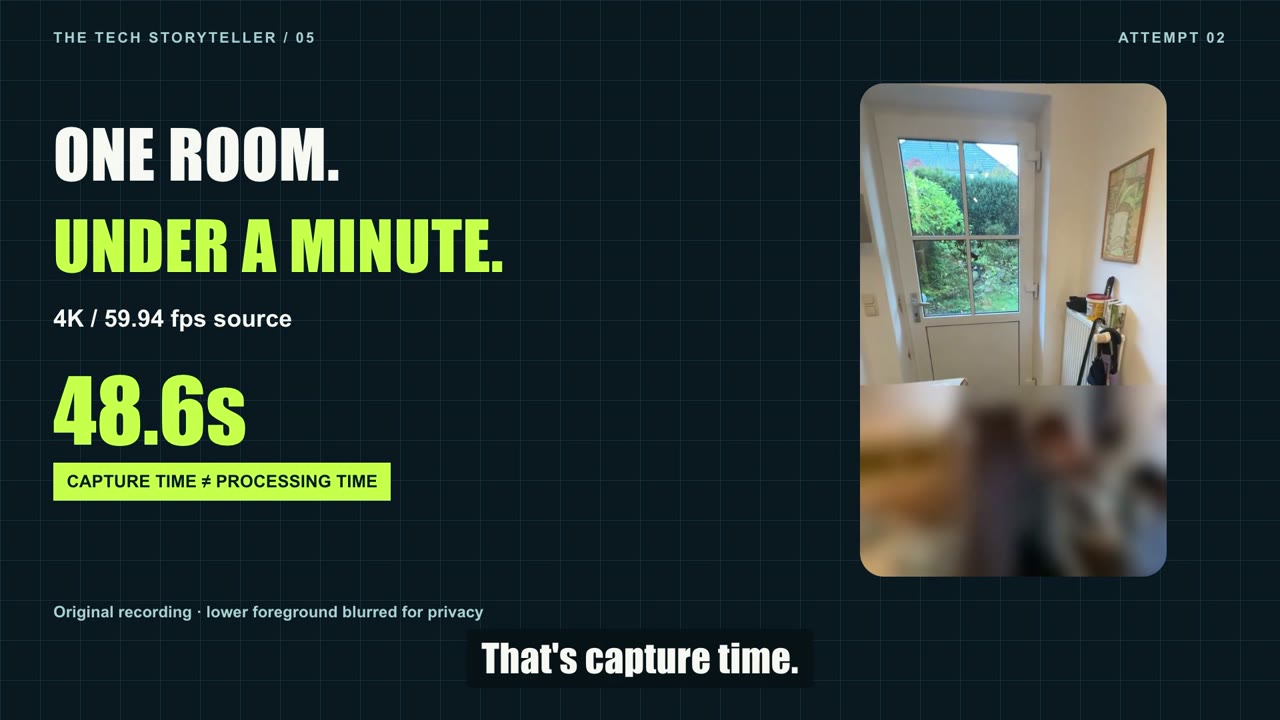
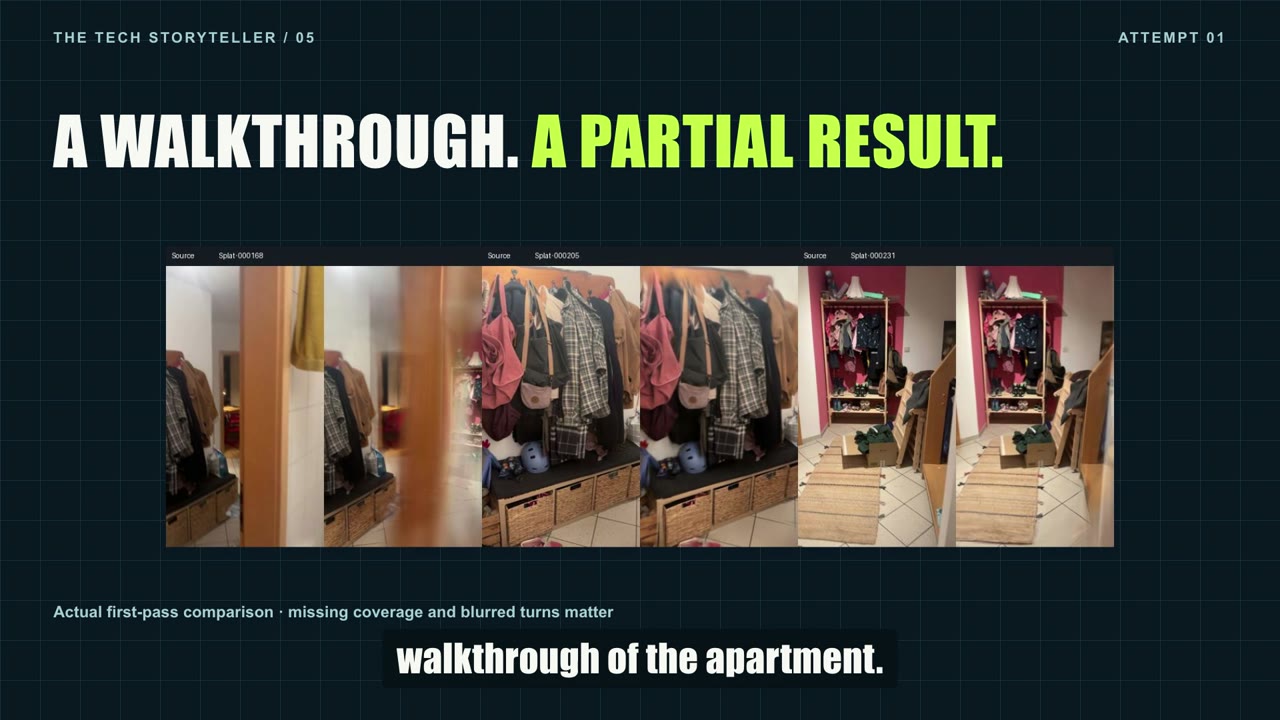
After fighting with LiDAR, I tried rebuilding a room from ordinary phone footage. The chosen capture was 48.6 seconds long, recorded in 4K at 59.94 fps. An incomplete first attempt made a more focused one-room recording useful.
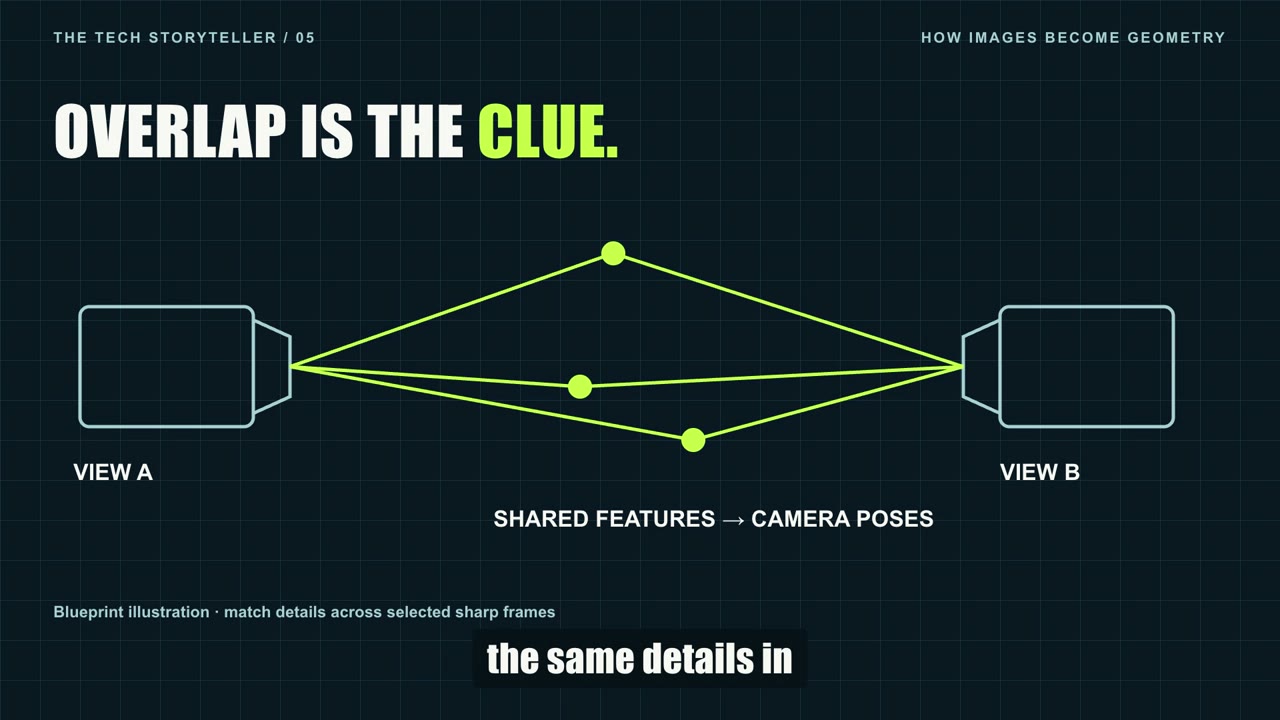
COLMAP aligned 187 of 195 selected images and produced 51,475 sparse points. Brush trained an appearance model with 400,000 Gaussians. The result could be explored from new viewpoints, with the limitations of what the camera had actually seen.
Those 48.6 seconds describe capture time, not reconstruction time. The output was not a verified solid model or a map with calibrated scale. A convincing Gaussian splat represents appearance; measured LiDAR geometry might complement it, but that fusion was the next question.
Read the detailed engineering field note →
Scope of this episode: Capture time is not processing time; not a metrically validated model.
Based on the published episode and its production record. YouTube publication verified 22 October 2026. Stills are extracted from the released episode. Captions distinguish recorded evidence, reconstruction, simulation and illustrative material.